






Physical AI is now an API call away

Today, Dream Labs is coming out of stealth with Dream-1, a robot foundation model that controls bimanual robots it has never seen, on tasks it was never shown, in places it has never been, from $3/hour.
Dream API is live for everyone, today. 🧵


Ayo retweeted

After six years in stealth, Atomic Machines is out. Our mission: on-demand, universal command of matter. First beachhead: the Matter Compiler, an AI-native manufacturing system that builds working micro-machines from code alone. No per-product tooling. No process development. Different code, different machine.
Ayo retweeted

AI is converging all CAD tools into one
Let’s go!

Add the motors, screens and screws, not just the board.
The parts library now includes off-board devices and hardware, like motors, displays, standoffs and screws.
Robotics builders can put the motors and display in the same project as the controller board that drives them.

ALT Flux card: Add the motors, screens and screws, not just the board. A Flux chat where a NEMA 17 stepper motor and an OLED display are added as off-board parts, and the BOM table that lists them with the STM32 and a capacitor.
Announcing a not-so-secret project we've been working on at @tnkrdotai. We're calling it the Tnkr IDE.
A tool for designing and deploying physical agents that can take on any body and be run by any physical AI model.
In this demo, you describe the agent you want to Leo. It recommends an embodiment, and if you want, you can iterate on the body with Leo to make it better.
Our prediction is that two things will happen over the next 12 months:
1. As hardware gets dramatically easier to build, more people will bring new embodiments for physical AI into the world, leading to a Cambrian explosion of form factors. We're only at the start of the curve. Microduck, Microban, Cubebot, Reachy Mini and Open Duck are early snapshots of what's to come.
2. As physical AI models mature, edge distribution becomes the next frontier. Developers need a simple way to harness these models to build things they want to see in their world. The same way coding models were harnessed through Cursor, Windsurf and Lovable.
Together, these lead to one outcome: physical agents of every shape, size and function running free in our world.
The Tnkr IDE is where they will all be described into existence, across hardware and intelligence orchestration.
Note: this is a rough demo, but hardware remixes are live on @tnkrdotai right now.
Back to work...
Excited to help get this in more hands ! @metrox_eth’s story is super inspiring.
I used to pick up litter in my street by hand and come home sunburnt. Now people will be able to build the robot that does it, from a box. Thank you @tnkrdotai.
Ayo retweeted
I used to pick up litter in my street by hand and come home sunburnt. Now people will be able to build the robot that does it, from a box. Thank you @tnkrdotai.

Fourth partnership for MOSS: @tnkrdotai.
MOSS started with @metrox_eth cleaning his street by hand, two or three hours under the sun. He didn't want to live in a dirty street, and he didn't want to burn either. So he built a robot.
The dream is simple. A parent and their kids build one over two or three weekends. There is electronics in it, programming, 3D printing, and at the end something useful rolls out the door. If everybody does something for their own street, the problem gets solved everywhere.
What stands in the way is more than a hundred printed parts, servos, bearings and a lot of screws to source alone. That's what Tnkr takes away: they turn open-source robots into kits, the parts in a box, with an assembly guide where you can look inside the robot.
MOSS stays fully open source. Build it from the files, or from the box.
And once it's in people's hands it won't only pick up litter. It will pick up toys in the living room, and things we haven't thought of.
We'll work hard with Tnkr over the coming weeks to make sure the kit meets its first makers soon, keeping quality and ease of assembly in mind.
Want one? Register your interest: link in the comment.
Thank you to the Tnkr team for betting on a small litter-picking rover.

Ayo retweeted
Today was mostly about modularity.
I’m building MOSS to be modular from day one, so getting started doesn’t mean buying exactly the hardware I use. Maybe you already have a Raspberry Pi lying around from another project. Maybe a more affordable depth camera fits your budget better.
Pi 5, with or without Hailo, or Jetson. RealSense or Gemini. Different combinations, same rover.
That’s what I committed to when I applied to the @OpenAIdevs Codex Physical Builds program. Here’s that idea taking shape.
Ayo retweeted

Fourth partnership for MOSS: @tnkrdotai.
MOSS started with @metrox_eth cleaning his street by hand, two or three hours under the sun. He didn't want to live in a dirty street, and he didn't want to burn either. So he built a robot.
The dream is simple. A parent and their kids build one over two or three weekends. There is electronics in it, programming, 3D printing, and at the end something useful rolls out the door. If everybody does something for their own street, the problem gets solved everywhere.
What stands in the way is more than a hundred printed parts, servos, bearings and a lot of screws to source alone. That's what Tnkr takes away: they turn open-source robots into kits, the parts in a box, with an assembly guide where you can look inside the robot.
MOSS stays fully open source. Build it from the files, or from the box.
And once it's in people's hands it won't only pick up litter. It will pick up toys in the living room, and things we haven't thought of.
We'll work hard with Tnkr over the coming weeks to make sure the kit meets its first makers soon, keeping quality and ease of assembly in mind.
Want one? Register your interest: link in the comment.
Thank you to the Tnkr team for betting on a small litter-picking rover.
Small robot. Useful work.
Built as a platform to learn locomotion and manipulation, with the dream of cleaning streets, one maker at a time.
From the chassis to the electronics, from the first grip to the drop: here’s a CAD preview of the first version of MOSS, our little tracked rover with an SO-101 robotic arm.
Next up:
The v0.5 CAD release. Files you can explore, print, modify and build upon.
The real MOSS driving on the beach (my agent stepping out into the real world for the first time).
MOSS is being built in the open, and you’re invited to be part of it. Build your own, bring your ideas, share your improvements, and help shape what comes next.
Ayo retweeted
MOSS is the first step in SCRAP: Street Cleaning Robotic Arm Platform.
Here’s what we’re building next:
Started two weeks ago: MOSS
An open-source robot for litter collection. Build together, break things, improve the hardware and collect data as a community.
Mid-October 2026: Go2 + OpenYAM
With Dimensional OS: autonomous mapping and navigation, litter classification and collection, fleet management and voice control.
November 2026: Start developing a larger platform
Built for roadsides and public spaces, keeping MOSS’s friendly character.
Thanks to @OpenAIDevs, @dimensionalos , @norma_core_dev and @tnkrdotai for supporting the project.
A @SHOW_ROBOTICS project.
We’ll share the builds, the tests and what we learn along the way.


The age of building atoms is officially upon us.
Building hardware will become a new medium of self expression and we need to build the systems to power it

Ayo retweeted

just seeing how other people wire their stuff and what actual component choices they make is a big value. hope this grows into a nice reference library

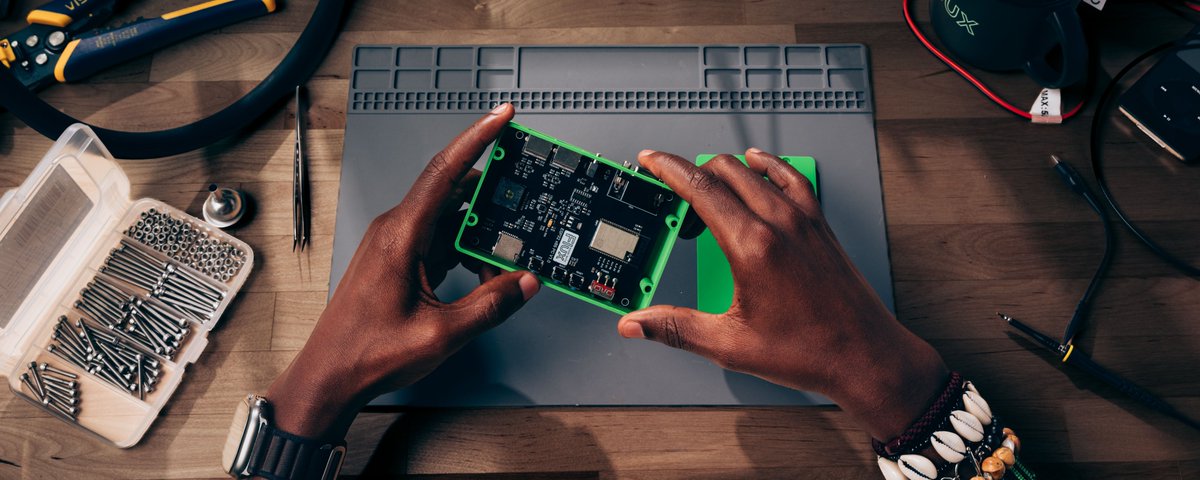
Electronics & wiring are the trickiest part of assembling a robot. We’re shipping an entirely new experience for electronics in your @tnkrdotai repository.
Goal is to make it 10x easier to document your electronics system & 10x easier for anyone to assemble.
Every team / builder needs this.
The best part is that it walks you through every step of the process. Wire by Wire.
Next step is mounting this on the robot's design so wiring paths are clearly defined. @tnkrdotai
Electronics & wiring are the trickiest part of assembling a robot. We’re shipping an entirely new experience for electronics in your @tnkrdotai repository.
Goal is to make it 10x easier to document your electronics system & 10x easier for anyone to assemble.
Every team / builder needs this.
Electronics & wiring are the trickiest part of assembling a robot. We’re shipping an entirely new experience for electronics in your @tnkrdotai repository.
Goal is to make it 10x easier to document your electronics system & 10x easier for anyone to assemble.
Every team / builder needs this.