
Robotics Ph.D. student at Carnegie Mellon!
Joined July 2019
- Tweets57
- Following146
- Followers69
- Likes2.5K


Pinned Tweet
Spot dressed up for Halloween!🎃 It's on a mission for its favorite 'candy'! 🔋 But two 'ghosts' were blocking the path…
A fun demo of our new paper on how robots can intelligently 'make way' on cluttered stairs! (1/4) @CMU_Robotics
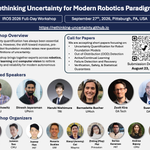
Do we still need Uncertainty Quantification for robotics? What does uncertainty mean in the modern robotics paradigm?
💡 We are organizing a workshop “Rethinking Uncertainty for Modern Robotics Paradigms” @ IROS 2026
Submit your work by Aug 23! 👇 (rethinking-uncertainty.githu…)

Organized by: Prasanna Sriganesh (CMU), @Junwon__Seo (CMU), Juyeop Han (MIT), Rosario Scalise (UW), Xiaoyi (Jeremy) Cai (Waymo), Zhiting (May) Mei (Princeton), Sertac Karaman (MIT), @andrea_bajcsy (CMU) | Matthew Travers (CMU)
🔗 Website & CFP: rethinking-uncertainty.githu…
Submission Deadline: August 23, 2026 (AoE)
Workshop Date: Sept 27, 2026
Location: Pittsburgh, PA
A planner then computes safe trajectories, which are executed by a learned pedipulation policy.
This tight coupling results in much higher success rates and lets the robot reclassify heavy 'immovable' objects. Here's a look at more technical results: (3/4)
See all the videos and details on our new project page: ➡️ prassi.me/clearing-clutter-o…
Full paper: 📷 arxiv.org/abs/2509.20516 (4/4)
#Robotics #Halloween2025 #AI
The code for our work on staircase perception is now public. This repository includes implementations from our papers on Bayesian staircase estimation and fast staircase detection.
Code: github.com/Prassi07/staircas…


Making robots safer on stairs! 💪 Our new work, just accepted to RA-L, introduces a clever way for robots to perceive the whole staircase, even when parts are hidden from view! 👀
Full paper: ieeexplore.ieee.org/document…
@CMU_Robotics
(1/4)
Bayesian Inference: We use this model with Bayesian inference to intelligently combine noisy sensor readings with prior knowledge about staircase already seen.
This combination lets us tackle challenges like occlusions, clutter, limited field-of-view and sensor noise.
(3/4)
But that's not all! We also use this information to segment the stair surfaces and remove clutter, enabling safer navigation on staircases. 🤖
Check out our project website for more info and images! 👉 prassi.me/bayesian-staircase…
(4/4)
Making robots safer on stairs! 💪 Our new work, just accepted to RA-L, introduces a clever way for robots to perceive the whole staircase, even when parts are hidden from view! 👀
Full paper: ieeexplore.ieee.org/document…
@CMU_Robotics
(1/4)
Prasanna Sriganesh retweeted

Hello all,
We are excited to organize the first workshop on Learning for Soft Robots at #CoRL2023! Through our amazing line-up of speakers, we hope to motivate future research in various soft robotic areas such as manipulation, locomotion, sensors, and embodied perception!

On the Friday of July 28th, I successfully finished my masters thesis on a staircase perception system for mobile robots.
Also, I'll be continuing as a Ph.D student at @CMU_Robotics this fall.


We finally have a social media presence. Follow to know more about our cool robots and the new work that's happening here!


Prasanna Sriganesh retweeted

A peek inside the MattLab nextpittsburgh.com/latest-ne…

If you're curious and want to see a few robots we have at the Mattlab in The Robotics Institute, here's a video.
youtu.be/aS8Z8RiCsXQ
This was covered by @NEXTpittsburgh
#Robotics #cmu