
We are the Interactive Robotics Group at MIT, a part of the Computer Science and Artificial Intelligence Laboratory (CSAIL) and the Aero/Astro Department.
Cambridge, MA
Joined November 2011
- Tweets332
- Following71
- Followers3.3K
- Likes92



MITRobotics retweeted

I'm really happy to share that our research has been published in the journal @Nature !
Why do you think the self-driving car stopped in this video? Because it detected the pedestrian? Or something else?
Hint: The glowing green concept is telling you what the car is detecting.
MITRobotics retweeted

.@MIT_CSAIL PhD candidate Felix Yanwei Wang is in the final year of his program working with the lab’s Interactive Robotics Group, researching robot learning, specifically inference-time policy alignment through human interactions.
Read more about Felix: bit.ly/445dEtA

MITRobotics retweeted

Want your robot to clean the kitchen your way? 🧹✨
🔗yanweiw.github.io/itps/"
Introducing Inference-Time Policy Steering: a training-free method that lets you specify where and how to manipulate objects, so you can guide non-interactive policies to align with your preferences!
MITRobotics retweeted

Excited to present our #NeurIPS2024 Oral talk! 🚀
Enhancing Preference-based Linear Bandits via Human Response Time
Coffee or tea? If you choose instantly, you likely have a strong preference. How can AI leverage this psychological insight to better learn human preferences?
Curious? Don't think too long! Let's connect and explore how psychology drives smarter AI.
📅 Dec. 11, 3:30-3:50 PM PST
📍 Oral Session 2A: Agents (East Ballroom A, B)
👉 Conference Session neurips.cc/virtual/2024/post…
👉 Paper on arXiv arxiv.org/pdf/2409.05798


Excited to share our new work: Enhancing Preference-based Linear Bandits via Human Response Time ⏱️🤖
@edgeyyzhang, Zhaolin Ren, Prof. Na Li, @ClaireYLiang, Prof. @julie_a_shah
👉 arxiv.org/abs/2409.05798
We show that human response times provide information about human preference strength, and speed up preference learning. This complements existing bandit algorithms that only learn from binary choices. We demonstrate this by integrating a psychology model (the EZ-Diffusion Model) into a bandit algorithm.
#AI #MachineLearning #RLHF #HumanFeedback #psychology #Bandits #Robotics #EZDiffusionModel

MITRobotics retweeted

Announcing Versatile Demonstration Interface (VDI) – a tool for collaborative robots that makes it easier to collect task demonstrations using three common Learning from Demonstration approaches.
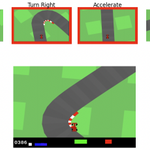
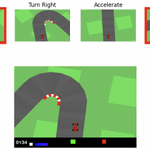
As another example, here the state is similar to the prototypes for "Accelerate" and "Turn Right", so the agent accelerates and turns right.
Our human study shows this research has the potential to help users predict out of distribution failures.

The work forces an agent to make decisions based on the current state's similarity to pre-defined human-interpretable prototypes.
For example, here the state is similar to the prototypes for "Brake" and "Turn Left", so the agent brakes and turns left.

** New ICLR Spotlight Paper 2023 **
Excited to announce our work building inherently interpretable Deep RL agents that doesn't sacrifice performance, and calibrates appropriate user trust.
(details below...)
openreview.net/forum?id=hWwY…
By @EoinKNNy, @MycalTucker, and @julie_a_shah
Talk to Serena at AAAI about how standard reward tuning via trial-and-error has many lurking dangers!
This quoted post is unavailable.
Neat work combining ideas from formal methods, stable control policies, and imitation learning!

How to guarantee successful imitation of multi-step tasks despite arbitrary perturbations?
1-2 demos + a logic formula of task specification.
See our #CoRL2022 oral talk today at 4:30p!
Paper: yanweiw.github.io/tli (with @robo_kween @shenli_robotics @ankitjs @julie_a_shah)
MITRobotics retweeted

Before everyone flees twitter... new paper coming out at NeurIPS!
Humans compress meanings into complexity limited discrete representations (words). Can neural nets learn similar communication? Yes! (1/7)
MITRobotics retweeted
Super grateful for this chance to continue exciting *interdisciplinary* research. Thanks to my advisor, @julie_a_shah, but also so many collaborators from other departments (@roger_p_levy and @NogaZaslavsky) and inspiring labmates and researchers.

Amazon and @MIT_SCC announced their first set of Amazon Fellows as part of their Science Hub, which aims to expand participation in AI, robotics, and other fields. They will receive funding to conduct independent research projects at MIT. Meet the fellows. #MachineLearning
MITRobotics retweeted
New journal paper on Latent Space Alignment! Neural agents learn latent representations spaces, but often each agent learns its own idiosyncratic space. How can we align those space among agents or even with humans? tandfonline.com/doi/full/10.…

MITRobotics retweeted
Happy to announce... Well, this paper didn't get in, but I still think it's neat. Using the same probe-based method for testing if language models use representations of syntax, we can "fix" RL agent perception (e.g., notice an oncoming car): arxiv.org/abs/2201.12938

MITRobotics retweeted
It's Monday morning, which means it's the perfect time to start thinking about information theory, brains, and neural nets! Submit to #InfoCog2022 @NeurIPSConf
Organized by @NogaZaslavsky @gershbrain
@sepalmerNeuro @C4COMPUTATION
sites.google.com/view/infoco…

MITRobotics retweeted

📣 Very excited to announce our in-person #NeurIPS2022 workshop on Information-Theoretic Principles in Cognitive Systems!
Check out our lineup of invited speakers and CFP, submit short papers by September 19
sites.google.com/view/infoco…
#InfoCog2022 @NeurIPSConf
MITRobotics retweeted
New paper (to appear in ICML)! Using a new prototype-based classifier, we show how notions of fair and hierarchical classification are tightly related, and how we can directly control "concept relationships" to switch between modes.

MITRobotics retweeted

What a great start of @ieee_ras_icra. The #icra2022 workshop on #cobots and @workofthefuture organised by @robo_kween, @julie_a_shah, Chris Fourie, Ben Armstrong & co-organisers was wonderful! sites.google.com/view/icra22…

And, research is more fun when its is interactive. That's why we released ExSum as a python package so that *you* can also play with it. More details on the project website: yilunzhou.github.io/exsum/!
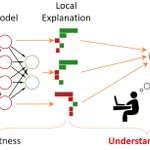
Overall, we propose understandability as a new dimension for evaluating local explanations. More details in the paper arxiv.org/pdf/2205.00130.pdf, or read the MIT news release on it news.mit.edu/2022/machine-le….