

Professor @BristolRobotLab | Visiting Fellow @oxfordrobots | Group Lead @CognitiveRobots
UK
Joined October 2010
- Tweets153
- Following309
- Followers323
- Likes357




Can neural networks reason like pointcloud registration algorithms?
Excited to share our latest paper, "NAR-*ICP: Neural Execution of Classical ICP-based Pointcloud Registration Algorithms", with @PetarV_93, @d_d_martini, and @kula78!
arxiv.org/abs/2410.11031
More info below 🤖

Lars Kunze retweeted

Today, CRG and @MRG_Oxford were on Broad Street demonstrating the ongoing RobotCycle project which is measuring cyclist safety around Oxford!
More info: ori.ox.ac.uk/projects/robotc…
Project leads:
@panefimia
@d_d_martini


🚗 Exciting News! 🚗
We’re thrilled to announce the CARLA RAI Autonomous Driving Challenge!
Evaluate driving agents against #responsibleAI (#RAI) indicators: carla-rai-challenge.github.i…
Paper: arxiv.org/pdf/2408.08584
@tas_hub @awscloud @carlasimulator @eval_ai
@SteadyBits @i_m_prs
Had a fantastic time at the #RoboTIPS event. Was great to see so many people from academia and industry as well as policymakers engaged in #ResponsibleRobotics. Congrats to @Marenka @alan_winfield and team! And huge thanks to @oxfordrobots for a demo on #causal #explainability!

Listening to @MichaelGroom16 giving a great talk on #safety for mobile manipulation for domestic robots at the @Dyson Institute of Engineering and Technology (dysoninstitute.com) at the AI and the Future of Engineering Symposium 2024.

The fabulous Jo-Ann Pattinson (linkedin.com/in/jo-ann-patti…) presented her #tas_rails work focussing on legal issues around #responsibleAI at the workshop on #NavigatingResponsibility (bit.ly/NavigatingResponsibil…) organised by the @tas_hub Computational Agent Responsibility project.

Excellent talk by Dr. Jo-Ann Pattinson (@ITSLeeds) about legal implications of AI-generated evidence for motor vehicle accident disputes
Last week, research fellows on our funded RAILS project attended the Trustworthy Autonomous System (TAS-R) workshop at the University of Leeds

🔎#Multimodal and memory-efficient #3D #semantic occupancy prediction for #autonomousdriving. Find out more in Sam's recent @IV_IEEE #IV2024 paper 👇
🚗 Today at IEEE IV 2024, Samuel Sze presented his paper, "Real-time 3D semantic occupancy prediction for autonomous vehicles using memory-efficient sparse convolution" 👏
📚 Check it out here: arxiv.org/abs/2403.08748
#IV2024 #IEEE #semanticsegmentation


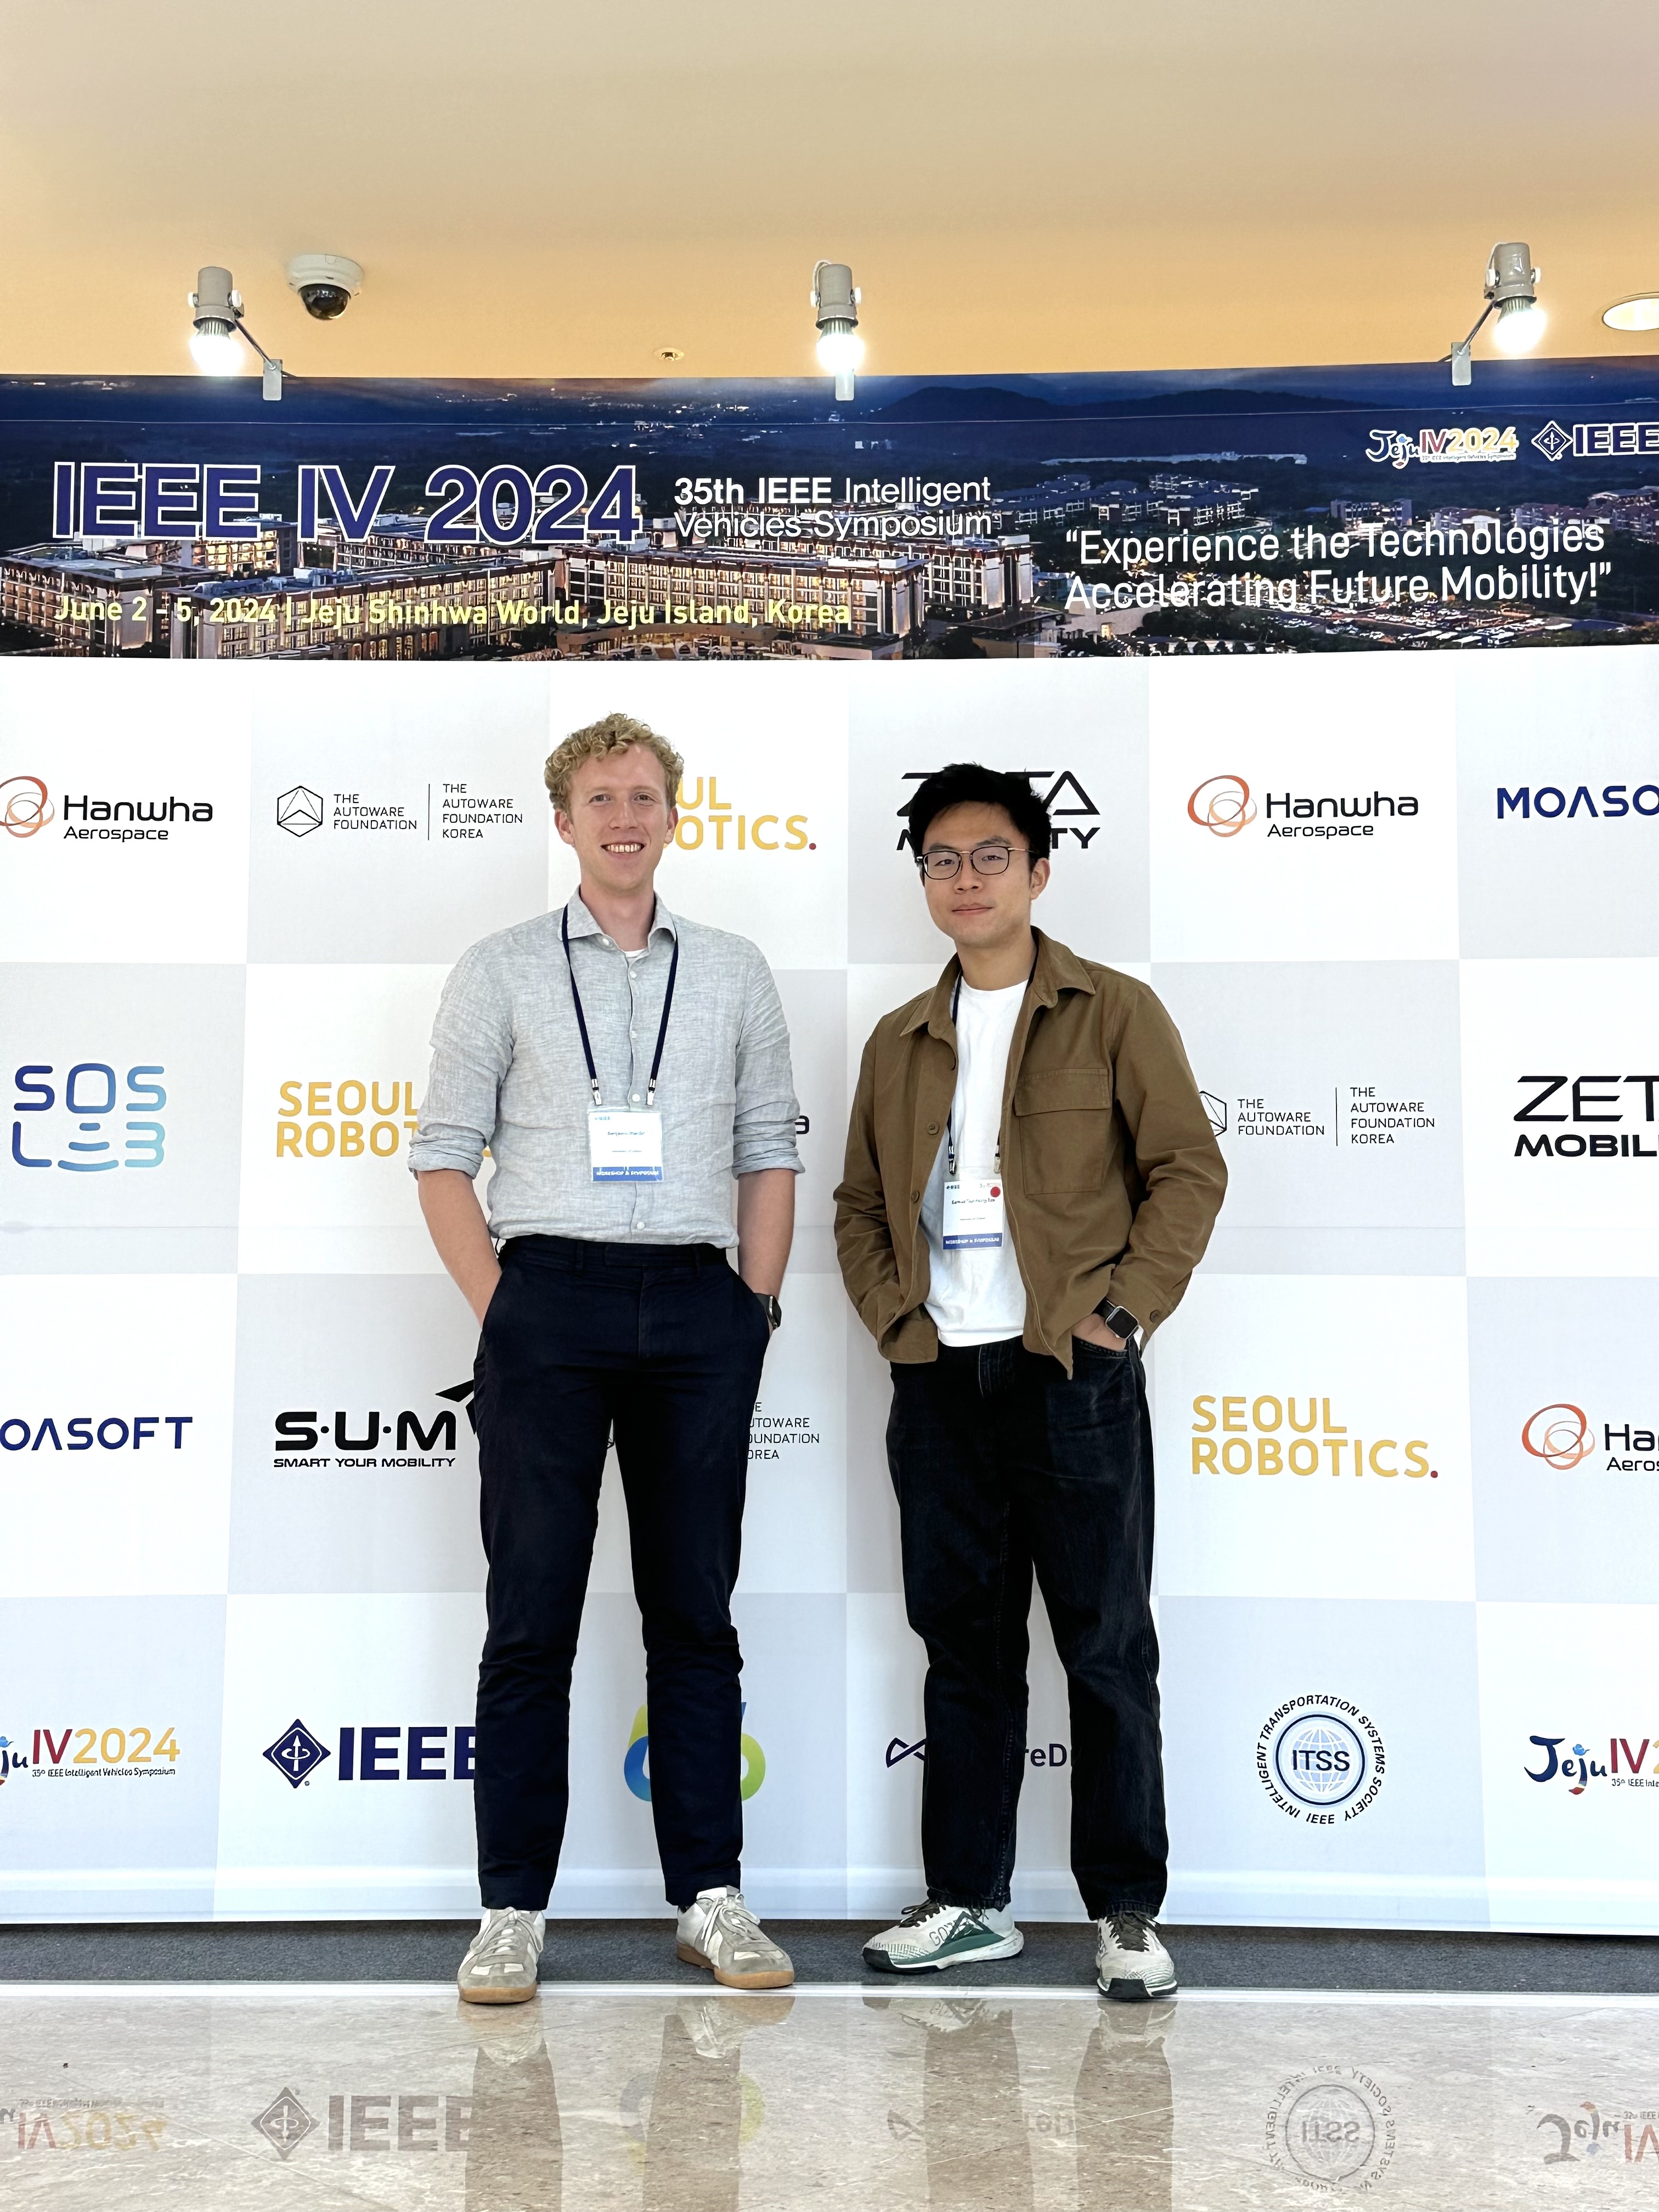
Great to see @b_b_hardin and Samuel Sze at @IV_IEEE #IV2024! Learn more about their work on #remotedriving and #cyclingsafety in the thread below...
📢 Live from Jeju Island, South Korea:
Two of our students, Benjamin Hardin @b_b_hardin and Samuel Sze are at the 2024 IEEE Intelligent Vehicles Symposium this week to present their work!
At today's sessions they presented two papers👇🧵
#IV2024 #remotedriving #cyclistsafety
If you are interested in #responsibleAI, #multimodal #LLMs, #RAG, and/or #explainability for #AutonomousSystems please check out our recent paper and code which will be presented at #RSS2024 @RoboticsSciSys
@tas_hub #tas_rails
This Post is from an account that no longer exists. Learn more


Thanks again for the invitation to this great and important workshop on Knowledge Representation and Reasoning for Robots at @eswc_conf #ESWC2024
@IAI_Bremen @CITEC_Bielefeld

Lars Kunze from Bristol / Oxford Robotics Institute in Action, giving a keynote at the workshop on Actionable Knowledge Representation for robots, collocated with @eswc_conf 2024. kr3-workshop.net/

Really enjoyed the talks and demos by @a2i_oxford, @dynamicrobots, #pnpl (@oiwi3000) and @CognitiveRobots

Thanks @BristolRobotLab for coming to visit yesterday! We loved all the questions and discussions. It was a great chance to share highlights from our research and demonstrate some of the new robots about the lab!


Very cool and much needed work on #causal learning & reasoning for robotic manipulation tasks by Maximilian Diehl and @KarinneRamirezA at #ICRA2024

Today at #icra2024, @panefimia presented our work on #RobotCycle. A first step to map and understand the impact of infrastructure and road user behaviour on #RoadSafety and #CyclingSafety. It's fantastic to see what the team has designed and developed under her leadership 🎉💪🙏

And very much looking forward to the next stage of this endeavour together with my co-lead @d_d_martini
Lars Kunze retweeted

Come and join us at #ICRA2024! Today, we have 2 works at the Field Robotics Workshop: @panefimia with "RobotCycle" and @mtt_gdd with "Watching Grass Grow". You can also find the papers on ArXiv at arxiv.org/abs/2403.07789 and arxiv.org/abs/2404.10446
Lars Kunze retweeted
At #ICRA2024? @panefimia will be at the Fields Robotics workshop presenting a poster about RobotCycle: assessing the safety of Oxford cyclists using a novel sensing unit and traffic modelling approach.
Come say hi between 9am to 1pm tomorrow (13/5)! 👋
arxiv.org/abs/2403.07789


On my way to #ICRA2024!! This year, we will be sharing insights on our #offroad #radar dataset (arxiv.org/abs/2403.02845), #RobotCycle (arxiv.org/abs/2403.07789), and risk-aware trajectory prediction. See you in #Japan!
@oxfordrobots @CognitiveRobots @BristolRobotLab

What a fantastic group!! Thank you all so much and looking forward to continuing the great work with you!!
Last week, the CRG celebrated our supervisor Lars Kunze @kula78 as he started a new position as a full professor with @BristolRobotLab.
Lars will continue leading the CRG as a visiting fellow, but please join us in celebrating his new role! 🎉 Congrats, Lars!
