
Graduate Researcher with Chuchu Fan at MIT @mit_REALM. Bringing Guarantees to Safe Reinforcement Learning 🇭🇰
Cambridge, Massachusetts
Joined April 2013
- Tweets51
- Following112
- Followers164
- Likes120




Oswin So retweeted

Neither @oswinso nor I could make it to ICLR this year, but our poster did make the trip 🤣✈️🇧🇷
Come by our poster today about #DAM (#Discrete #Adjoint #Matching)—a unifying AM for discrete generative models (e.g., dLLM) !!
🕒 3:15 PM – 5:45 PM
📍 Pavilion 3 P3 #1711


Adjoint Matching works great for fine-tuning diffusion models with reward gradients.
How about #AM for #diffusionLLMs with #nondifferentiable #rewards? Does "discrete adjoint" even exist ... and how? 🤔
📢 Introduce #DiscreteAdjointMatching (#DAM)—a unifying AM for discrete generative models, accepted to #ICLR2026 🇧🇷
Work done with my amazing intern @oswinso and @RickyTQChen, Brian, Chuchu 🙌
📰 arxiv.org/abs/2602.07132
Oswin So retweeted

Robots can plan, but rarely improvise. How do we move beyond pick-and-place to multi-object, improvisational manipulation without giving up completeness guarantees?
We introduce Shortcut Learning for Abstract Planning (SLAP), a new method that uses reinforcement learning (RL) to discover shortcuts in the planning graphs induced by task and motion planning (TAMP) skill libraries. It is a plug-and-play module that can be trained on top of existing planners to speed up execution through learned shortcuts.
(1/5)
Oswin So retweeted

Meet Casper👻, a friendly robot sidekick who shadows your day, decodes your intents on the fly, and lends a hand while you stay in control!
Instead of passively receiving commands, what if a robot actively sense what you need in the background, and step in when confident? (1/n)
Oswin So retweeted

🏆 Huge congratulations to the #RSS2025 Award Winners!
roboticsconference.org/progr…


Oswin So retweeted

#almostsure blog post: On the integral ∫I(W ≥ 0) dW
This looks at the mentioned integral, which displays properties particular to stochastic integration and which may seem counter-intuitive.
almostsuremath.com/2023/11/0…

Suppose now that Xₜ is started from ε:
Xₜ ≔ ε + ∫₀ᵗ 1{Wₛ >= 0} dWₛ
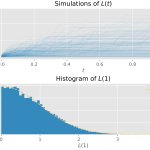
Since Xₜ = ε + max(W_t,0) - ½ L(t) and L(t) strictly increases only when Wₜ=0, does there exist a time u such that
Xᵤ ≥ Wᵤ AND Xᵤ < 0?
xitter.cf/oswinso/status/1721265…


More observations and questions on the following stochastic integral:
Xₜ ≔ ∫₀ᵗ 1{Wₛ >= 0} dWₛ
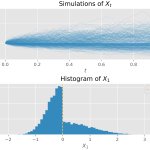
Numerically simulating this does confirm that E[Xₜ]=0 and Xₜ does go negative. What I did not expect, however, is the distribution of Xₜ to look the way it does.

Oswin So retweeted
Momentum Schrödinger Bridge is a nice framework for multi-marginal distribution matching (e.g. population modeling) that overcomes the stiff trajectories induced by most pair-wise distribution matching methods.
Fun project with @iamct_r @MoleiTaoMath & Evangelos 🌉🌝

😀 #NeurIPS2023 Introducing our work #DMSB (arxiv.org/abs/2303.01751)!
#DMSB is an extension of Schrödinger Bridge algorithm (arxiv.org/abs/2110.11291 and arxiv.org/abs/2106.01357) in phase space to tackle trajectory inference task!
Oswin So retweeted

New blog post: Yet Another ICML Award Fiasco
The story of the @icmlconf 2023 Outstanding Paper Award to the D-Adaptation paper with worse results that the ones from 9 years ago
Please share it to start a needed conversation on mistakenly granted awards
parameterfree.com/2023/08/30…

Oswin So retweeted

What is variational optimization?
Why can continuous dynamics help?
Optimization is already a profound field, what can it bring in?
Check out blog itsdynamical.github.io/artic…
Comment/Retweet/Like will be deeply appreciated!
1/6
Epigraph form provides a stable way of solving constrained optimal control problems to find safe, stabilizing controllers. We investigate this in our work accepted to #RSS2023.
Project: mit-realm.github.io/efppo
Paper: arxiv.org/pdf/2305.14154.pdf
MIT News: news.mit.edu/2023/safe-and-r…