

Reliable Autonomous Systems Lab (REALM) @MIT. We design, analyze and verify safe control systems.
Cambridge, Massachusetts
Joined September 2022
- Tweets29
- Following407
- Followers162
- Likes18


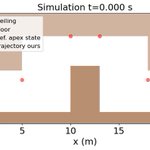

Excited to present two works at #CoRL2023, both at Poster Session 6 on Thursday 4:15 pm!
🧵 (1/7)
By predicting a diverse set of possible failures prior to deployment, we can make sure robots of all sizes (from drones to power grids) stay safe.
🧵 (6/7)

Our code is open source!
Code: github.com/MIT-REALM/archite…
Arxiv: arxiv.org/abs/2309.08052
Web: mit-realm.github.io/breaking…
Video: youtu.be/gzhRVMUwqG0
🧵 (7/7)
Reliable Autonomous Systems Lab at MIT (REALM) retweeted
An @MITAeroAstro team developed a machine-learning technique that can autonomously fly a plane through a difficult “stabilize-avoid” scenario while avoiding obstacles.
Read more at MIT News news.mit.edu/2023/safe-and-r…
Reliable Autonomous Systems Lab at MIT (REALM) retweeted

Great @l4dc_conf talk by @mit_REALM PhD student Songyuan Zhang


REALM has two strong works being presented at @l4dc_conf this year. @YueMengTHU 's “Hybrid Systems Neural Control with Region-of-Attraction Planner” and Songyuan Zhang’s “Compositional Neural Certificates for Networked Dynamical Systems” will be presented! To learn more... (1/2)
A huge number robotics problems can be modeled as hybrid dynamical systems, and these are known to be difficult to define controllers for. In @YueMengTHU ‘s new work (accepted to L4DC), we have developed a method for designing controllers for this important class of systems!
And further information can be found here: mit-realm.github.io/hybrid-c…
Please attend @l4dc_conf, if you're interested in hearing from Yue first-hand!
An exciting question that came from a vigorous discussion at REALM last week:
What differentiable simulators exist that can model soft robotic systems interacting withe the world?
(1/3)
#AcademicChatter #RoboticsChatter #DifferentiableSimulation
Context: REALM has established its passion for differentiable simulation in several different results (see our work on Architect) and we were having a spirited discussion last week about how better sensor placement/design might be possible if we had a good (2/3)
enough soft robot simulator. (3/3)
xitter.cf/mit_REALM/status/15849…

Sound interesting? Then, play around with his implementation of this work which is located in REALM’s Architect repository: github.com/MIT-REALM/archite…
