

phd @McGillU and @mila_quebec, working on rl and robot learning
Montréal, Québec
Joined February 2017
- Tweets637
- Following847
- Followers294
- Likes4.3K






Pinned Tweet
📢 New paper out!
We introduce QWM: a single locomotion world model trained across 8 quadrupeds and deployed zero-shot on robots it had never seen by conditioning on their morphology specs: ANYmal-D and Unitree Go1 🦾
No fine-tuning, no warm-up, no retraining from scratch.
The key insight: robot morphology isn't a latent variable to infer from motion history, it's a known engineering spec sitting in the USD (or URDF) file. So we just use it directly.
my co-first author at NeurIPS didn't get the invitation from the waitlist to register meaning he can't attend a conference he has a paper in. wondering who got it.
i thought the whole point of having 3 locations was to accommodate everyone. apparently publishing a paper doesn't guarantee you can actually attend your own conference.
really frustrating and ridiculous!
Mohamad H. Danesh retweeted

🎉 The CoRL 2026 accepted papers are out!
📄 687 papers
🎤 21 orals
✨ 72 spotlights
See you in Austin, Nov 9–11. Congrats to all authors 👏
corl.org/program/accepted-pa…
#CoRL2026


Make RL inside world models great again!
sites.google.com/view/uncert…

Hence the question:
which is better: a roboticist who learns AI, or an AI person who learns robotics?

Mohamad H. Danesh retweeted

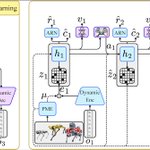
In our latest work at @corl_conf, we introduce Quadrupedal World Model: a single morphology-conditioned dynamics model, where policies are trained entirely in imagination.
We found generalization emerges by conditioning the dynamics, not the policy.
🔗modanesh.github.io/papers/qw…

Mohamad H. Danesh retweeted

🌐Does modeling dynamics provide a better path to generalization than learning model-free policies alone?
🐕In QWM @corl_conf, a morphology-conditioned world model learns shared locomotion dynamics and enables zero-shot transfer to unseen morphologies.
🔗modanesh.github.io/papers/qw…
What if one world model could control many different robots? 🤖🌍
That's QWM.
In this 2 minutes video we show keypoints about QWM: learning across heterogeneous quadrupeds, and transferring zero-shot to unseen morphologies.
No fine-tuning. No warm-up. No retraining.
Let's talk it further at CoRL 🥳
Checkout the website here:
🔗 modanesh.github.io/papers/qw…

Singularity is here

We’re releasing a broad range of new mathematical results produced by an internal frontier model.
We’ve been consulting with the independent Advisory Group on Mathematics and Artificial Intelligence at the Institute for Advanced Study, and we have drawn on their advice and public recommendations to inform how we release these results.
github.com/openai/math

🚀 Hetero-IsaacLab v0.3 is out!
Expanded the framework beyond quadrupeds to support heterogeneous humanoids as well:
Unitree H1, Unitree H2, Unitree G1, Cassie, Digit
You can now train policies across different morphologies in a signle heterogenous environment:
🌐github.com/modanesh/Hetero-I…
Mohamad H. Danesh retweeted

Drift Q-Learning just got into #Neurips26 ! 🇦🇺
I guess see you in Australia!!
Project Page: driftql.github.io/

Mohamad H. Danesh retweeted

For years, Digit had a bird-like stance, tuned for efficient, dynamic motion. Digit 5 is being engineered with a redesigned leg for the other half of real work: squatting low and lifting heavy, the way a person does when the load's on the floor.
Thanks to @bheater and @a3automate for the coverage.
automate.org/robotics/indust…


Mohamad H. Danesh retweeted

At this year's Montreal Robotics Summer School, teams programmed a Unitree Go1 to walk itself to dinner — sim2real RL, vision-based nav, AprilTags and all. Congrats to our Winning teams (5 & 6)! Full recap 👉 fracturedplane.com/blog/2026…
#Robotics #ReinforcementLearning #Mila

Accepted to CoRL! 🥳
See you in Austin!
📢 New paper out!
We introduce QWM: a single locomotion world model trained across 8 quadrupeds and deployed zero-shot on robots it had never seen by conditioning on their morphology specs: ANYmal-D and Unitree Go1 🦾
No fine-tuning, no warm-up, no retraining from scratch.
The key insight: robot morphology isn't a latent variable to infer from motion history, it's a known engineering spec sitting in the USD (or URDF) file. So we just use it directly.
Mohamad H. Danesh retweeted
Mind blowing 🤯
This is killing research in many academic labs. Nor do I believe any published research was ever close to this, regardless of the posted videos.
Does it still make sense to work on sim-to-real locomotion?

Mohamad H. Danesh retweeted
Great talk by Scott Fujimoto at our World Models + Model-Based RL workshop explaining what world models are.
A great day of talks going on @UMontreal 🇨🇦!
#RLC2026

Our workshop on world modeling in RL just started!
Come join us to hear the latest on world modeling from the experts and have productive discussions in our poster sessions.
📍 B-4335, 3200 Jean-Brillant, Université de Montréal

Mohamad H. Danesh retweeted
I’m at Reinforcement Learning Conference in Montreal this week! 🇨🇦
Come to our Model-Based RL workshop tomorrow!
Our speakers are cool!!
📢 Call for Papers! #RLC2026 🇨🇦
🌎 We are now inviting contributions to the Workshop on Model-based RL in the Era of Generative World Models at @RL_Conference in Montreal, Canada! 🇨🇦
🔗 Webpage
worldmodels-rlc.github.io/
📄 Submit paper now!
openreview.net/group?id=rl-c…
🧵Format
