
System + Robotics Phd & Postdoc @UCBerkeley | @UCLA Alumni
Berkeley, CA
Joined August 2022
- Tweets26
- Following261
- Followers312
- Likes90




Pinned Tweet
We gave Claude and GPT a phone video of a robot wiping. In an hour, each built a full-dynamics digital twin.
Introducing RoboSimStudio 🤖: an open and interactive toolkit for Agentic Robotics, enabling Fable, Astra and Argon AI agents to model sponges 🧽, cables 🧵 and cloth 👔.
Kaiyuan Eric Chen retweeted

😫Tired of spending hours teleoperating robots?
🚀What if you could collect 2.9× more demonstrations with the same human effort?
Introducing TANDEM: our new work that combines autonomous task and motion planning (TAMP) with human teleoperation only when needed. 🧵 1/n

Kaiyuan Eric Chen retweeted

Gemini-4 Argon shows a large improvement in robotics understanding on RoboVista.
It reaches 81.9%, beats GPT-6 Astra and Claude Fable 5.1 in our evaluation with lowest eval cost. Compared with Gemini 3 Flash, it improves across every robotics domain. Example VQA👇


🤖How well do today's VLMs actually understand real-world robotics? 👀
Excited to share RoboVista at #RSS2026 — a systematic evaluation and benchmark for VLMs across diverse, real-world robot applications. Website, dataset and paper: berkeleyautomation.github.io…
Developed by researchers at @UCBerkeley, @GoogleDeepMind, and @Princeton. 🧵👇
The paper, code, examples, and interactive 3D rollouts are all open
🌐 Site, 📄 Paper, 🎮 Demo: robosimstudio.github.io
💻 Code: github.com/robosimstudio/rob…
Thanks to the great team!
@eric_heiden @erwincoumans @milesmacklin #spencer_huang from @nvidia @NVIDIARobotics and
@Shuangyu0_0Xie, @UksangYoo, @XinyueZhuXY , Cael Magner, @alvinyzhu , @talking_kim, and @Ken_Goldberg from @UCBerkeley @berkeley_ai
I will be presenting RoboVista at #RSS2026 today! This joint work with @GoogleDeepMind assess how effectively current VLMs process diverse robotic applications (esp. field robotics!) . Fun fact: most of all annotators already have PhD degrees. Come talk to me at poster session!
🤖How well do today's VLMs actually understand real-world robotics? 👀
Excited to share RoboVista at #RSS2026 — a systematic evaluation and benchmark for VLMs across diverse, real-world robot applications. Website, dataset and paper: berkeleyautomation.github.io…
Developed by researchers at @UCBerkeley, @GoogleDeepMind, and @Princeton. 🧵👇
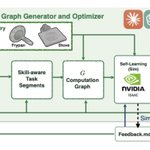
Graph-as-Policy (GaP) is a new variant of Agentic Robotics from @NVIDIA and @UCBerkeley that builds computation graphs (like ROS) to ensure modularity, manage complexity, and facilitate interpretability.
🧵Open code and paper: graph-robots.github.io/gap/
#Robotics #Automation #AgenticAI #EmbodiedAI
The paper, more demo videos, 8 benchmarks, the skill library, and the code are all open. 🔓
🌐 Site: graph-robots.github.io/gap/
📄 Paper: arxiv.org/abs/2607.05369

Thanks to the great team !
including: @UksangYoo @ruwantw from @BoschGlobal
@guanzhi_wang @Adithya_Murali_ @balakumar_ @yukez @DrJimFan #spencer_huang from @nvidia
@Shuangyu0_0Xie @letian_fu @uynitsuj @talking_kim @sandeep_b24 @HaoruXue from and @Ken_Goldberg from @UCBerkeley
How GaP works:
🗣️ Task Description: Describe a task (e.g., "make popcorn - repeat"), workcell, object and pose range, and provide a set of model-based and model-free skills.
🧠 Multi-Agent Orchestration: A multi-agent harness, built over coding tools like #Claude and #Gemini, decomposes a special prompt and assembles an interpretable computation graph from an open skill library
🔄 Self-Learning in Sim: The graph is rehearsed in simulation, using contact feedback to diagnose its own failures, and rewrites its own structure until performance plateaus.
🦾 Sim-to-Real: The optimized graph is then exported to run on the physical robot.
GaP can provide the interpretability and reliability of classical engineering, but with coding agents doing the authoring and fine tuning. 🤯


Kaiyuan Eric Chen retweeted

📍 𝗖𝗮𝗻 𝗔𝗜 𝗡𝗮𝘃𝗶𝗴𝗮𝘁𝗲 𝗠𝗮𝗽𝘀 𝗟𝗶𝗸𝗲 𝗛𝘂𝗺𝗮𝗻𝘀 𝗗𝗼? 𝗜𝗻𝘁𝗿𝗼𝗱𝘂𝗰𝗶𝗻𝗴 𝗠𝗮𝗽𝗕𝗲𝗻𝗰𝗵! 🗺️🤖
𝘙𝘦𝘢𝘥𝘪𝘯𝘨 𝘮𝘢𝘱𝘴, like Google Maps and Theme Park Maps, is second nature for humans. It is a highly challenging task that requires visual understanding, spatial reasoning, and long-horizon planning. We're curious - 𝗖𝗮𝗻 𝗟𝗮𝗿𝗴𝗲 𝗩𝗶𝘀𝗶𝗼𝗻-𝗟𝗮𝗻𝗴𝘂𝗮𝗴𝗲 𝗠𝗼𝗱𝗲𝗹𝘀 (𝗟𝗩𝗟𝗠𝘀) 𝗱𝗼 𝗶𝘁 𝘁𝗼𝗼? 🤔
We’re excited to share 𝗠𝗮𝗽𝗕𝗲𝗻𝗰𝗵, the first-ever dataset and benchmark specifically designed for evaluating how well LVLMs perform on pixel-based map navigation tasks! 🚀
🔑 𝗪𝗵𝘆 𝗠𝗮𝗽𝗕𝗲𝗻𝗰𝗵 𝗶𝘀 𝗮 𝗚𝗮𝗺𝗲-𝗖𝗵𝗮𝗻𝗴𝗲𝗿:
• 📌 1600+ Complex Pathfinding Queries from 100 uniquely challenging map scenarios (urban areas, theme parks, universities, malls, and more).
• 📌 Introduces Map Space Scene Graph (MSSG): a novel data structure for mapping visual landmarks and spatial relationships to structured navigation tasks.
• 📌 Evaluates state-of-the-art LVLMs like GPT-4o, Llama-3.2, and Qwen-2-VL under zero-shot and Chain-of-Thought (CoT) reasoning methods, revealing key insights into their spatial reasoning and navigation abilities.
🚩 𝗞𝗲𝘆 𝗜𝗻𝘀𝗶𝗴𝗵𝘁𝘀:
• Despite their impressive capabilities, current LVLMs struggle significantly with spatial reasoning and structured decision-making.
• CoT prompting boosts spatial reasoning performance but sometimes introduces redundant details.
👀 𝗖𝗵𝗲𝗰𝗸 𝗼𝘂𝘁 𝗼𝘂𝗿 𝗳𝗶𝗻𝗱𝗶𝗻𝗴𝘀, 𝗱𝗮𝘁𝗮𝘀𝗲𝘁, 𝗮𝗻𝗱 𝗰𝗼𝗱𝗲 𝗵𝗲𝗿𝗲:
🔗 Arxiv: lnkd.in/gBv-sFJ3
Huge thanks to our incredible collaborators for making this happen, from @TAMU, @UCBerkeley, @mbzuai, @UMich, and @UCRiverside! 🎉
Let’s continue to bridge the gap between human intuition and AI navigation! 🗺️💡

Kaiyuan Eric Chen retweeted

Releasing a guide for scaling LLM embedding generation by 9x compared to autoscaling cloud services:
⚡️9x more GPUs ➡️ 9x speedup
💰61% cost reduction with spot
The secret? Going multi-region with @skypilot_org to overcome single-region capacity limits.
blog.skypilot.co/large-scale…

ALT https://blog.skypilot.co/large-scale-embedding/
Kaiyuan Eric Chen retweeted
New model: Spin up Gemma 3 in your cluster/cloud
$ sky launch gemma3.yaml
docs.skypilot.co/en/latest/e…

Gemma 3 is a collection of lightweight, state-of-the-art open models built from the same research and technology that powers our Gemini 2.0 models. → goo.gle/43Ic5RV