





Excited to share two papers accepted to CoRL 2026! 🎉
1. 𝗚𝗮𝗣: 𝗔 𝗚𝗿𝗮𝗽𝗵-𝗮𝘀-𝗣𝗼𝗹𝗶𝗰𝘆 𝗠𝘂𝗹𝘁𝗶-𝗔𝗴𝗲𝗻𝘁 𝗦𝗲𝗹𝗳-𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴 𝗛𝗮𝗿𝗻𝗲𝘀𝘀 𝗳𝗼𝗿 𝗩𝗮𝗿𝗶𝗮𝘁𝗶𝗼𝗻𝗮𝗹 𝗔𝘂𝘁𝗼𝗺𝗮𝘁𝗶𝗼𝗻 𝗧𝗮𝘀𝗸𝘀
Website : graph-robots.github.io/gap/

2. 𝗥𝗲𝗰𝗼𝘃𝗲𝗿, 𝗗𝗶𝘀𝗰𝗼𝘃𝗲𝗿, 𝗣𝗹𝗮𝗻: 𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴 𝗦𝗸𝗶𝗹𝗹𝘀 𝗮𝗻𝗱 𝗖𝗼𝗻𝗰𝗲𝗽𝘁𝘀 𝗳𝗿𝗼𝗺 𝗥𝗼𝗯𝗼𝘁 𝗙𝗮𝗶𝗹𝘂𝗿𝗲𝘀
Website: jaraxxus-me.github.io/ReSYNC…
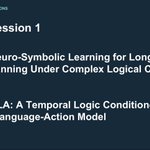
Announcing Best Paper Award at IROS ReS AI workshop.
Best Paper: “iFlax: Neuro-Symbolic Learning for Long-Horizon Task Planning Under Complex Logical Constraints”
Thanks Carnegie Bosch Institute for sponsoring the best paper award.
Congratulations! 🎉
#IROS2026 #ReSAI2026


Interesting panel discussion happening now at IROS ReS AI on what semantics must the data capture for efficient robot learning, and how important is human input?
Panelists: @smash0190, @prof_yz , @maojiayuan, and Alessandra Sciutti, moderated by @jeanoh.

Namai Chandra is presenting his work on “ActionGround: Training-Free Runtime Refinement of Frozen VLA Policies” in the second oral session of IROS ReS AI 2026.
#ReSAI2026 #IROS2026

IROS ReS AI second oral talks session just stated with Guy Azran presenting his work on “Task-Aware Conformal State Estimation for Reliable Robotic Planning”
#IROS2026 #ReSAI2026

IROS ReS AI Poster session is happening now at Room 411.
#IROS2026 #ReSAI2026

The fifth keynote at IROS ReS AI 2026 by Dr. Joyce Chai from @michigan_AI on “Language Guided Failure Recovery in Robots”
Stay tuned for an exciting poster session, followed by the second oral talks session and panel discussion.
#IROS2026 #ReSAI2026

Fourth keynote at the ReS AI workshop by Dr. Yezhou (YZ) Yang (@prof_yz) on “Evaluating AI (and AI Evaluation) as a Science: Towards Science-guided Reliable Agents”.
#IROS2026 #ReSAI2026


Third keynote at the IROS ReS AI workshop by Dr. Jiayuan Mao (@maojiayuan) from the University of Pennsylvania on “Integrated Learning and Planning with Neuro-Symbolic Concepts”.
#ReSAI2026 #IROS2026

Second keynote at the IROS ReS AI workshop by Dr. Sebastian Scherer (@smash0190) from the Robotics Institute at CMU on “Why robots need symbols: finite memory, long horizons, and the limits of scale”
#ReSAI2026

First keynote at IROS ReS AI 2026 workshop by Dr. Alessandra Sciutti from the Italian Institute of Technology on “Grounding Meaning through Embodied and Social Cognitive Development”
#IROS2026 #ReSAI2026

IROS 2026 the first workshop on Embodied Neuro-Symbolic AI for Reliable and Safe Robotics (ReS AI) is happening now in room 411 at the David L. Lawrence Convention Center, in vibrant Pittsburgh!
#IROS2026 #ReSAI2026 #EmbodiedNeurosymbolicAI


Ruwan Wickramarachchi retweeted

Through the VOICE trial, Terry is using his Neuralink implant to help fine-tune a brain-to-voice interface for himself and others who can’t speak. He trained the algorithm first by miming speech as best he could, then by simply thinking the words and hearing them come out in his own natural voice.
Powered by Grok Voice from @spacexai
Check out our latest work on GTA-2 — zero-shot robot skill synthesis with VLMs, demonstrated across 14 real-robot tasks!
📄 Paper: arxiv.org/abs/2609.09808
🌐 Project webpage: gta2-project.github.io


We introduce GTA-2, a multi-VLM framework that synthesizes executable robot manipulation skills from reusable, object-centric task-axis components
Zero-shot, no task-specific demonstrations or training.
gta2-project.github.io 🧵 1/9
The deadline has been extended to August 28, 2026, 23:59 AoE.
