

General World Models. We're hiring: https://xitter.cf/t.co/RgSGZylruH
Joined June 2023
- Tweets493
- Following0
- Followers11.8K
- Likes1.8K





Pinned Tweet
Our first-party foundation model is controlling this robot to make coffee, fully autonomously.
We are looking for robotics teams to work with on real world applications. Tell us what you are building. bagel.com/partner


This fully autonomous demo shows a Bagel Labs foundation model controlling a robot to make coffee.
We previously released WorldDiT, our lightweight architecture for robot foundation models. At the time of release, it was on the Pareto frontier for model size and performance. We have since been refining this architecture to handle longer
horizon, more useful tasks fully autonomously.
Making coffee means getting a whole sequence of actions right. Each step depends on the result of the last, so small mistakes can build up as the task continues. Getting this to work with a small model is especially challenging. This demo is an example of what the model can do today.
If you are deploying robots or have existing hardware you want to make autonomous, we would like to partner with you. bagel.com/partner
bagel.com retweeted
Toronto Robotics night was back for ROSCon. And it was a blast!


ROSCon is in Toronto this week. Tonight, we’re hosting Toronto Robotics Night for people here for the conference and the local robotics community.
Come by after the sessions for drinks and appetizers. We start at 6:30, a 5 minute walk from the ROSCon venue.
RSVP to join: luma.com/501ufk17

ROSCon is in Toronto this week. Tonight, we’re hosting Toronto Robotics Night for people here for the conference and the local robotics community.
Come by after the sessions for drinks and appetizers. We start at 6:30, a 5 minute walk from the ROSCon venue.
RSVP to join: luma.com/501ufk17
bagel.com retweeted

we're hosting a ROSCon special edition of Bagel's Toronto Robotics Night this week!
we're gathering people who are globally shaping physical AI in one room to wrap up the conference together
for researchers, founders, robotics engineers, and builders
RSVP here: luma.com/501ufk17
bagel.com retweeted
The first toronto robotics night was a grand success!


Some of the most interesting work in robotics now sits between world models and real machines.
We’re bringing the people working on both together this Thursday at the first ever Toronto Robotics Night.
Come by if you're in town : luma.com/83qrbegr


Some of the most interesting work in robotics now sits between world models and real machines.
We’re bringing the people working on both together this Thursday at the first ever Toronto Robotics Night.
Come by if you're in town : luma.com/83qrbegr
bagel.com retweeted
Hardware is a big constraint in robotics, that's why we don't think the answer will be increasingly larger VLM models as action backbones.
We tried to solve that issue with WorldDiT, which is at the pareto frontier for size-performance. Now I want to see how far we can scale it without losing this tradeoff.
Here's a simulation demo.
bagel.com retweeted
The new WorldDiT robotics model is really cool:
It's very small (< 1B parameters), yet it can perform prediction and control in a single model.
• It can predict how the world will change
• It then decides what the robot should do
Models are getting smaller and more capable. We are doing more with way less.
We are releasing WorldDiT, a unified architecture for robotics world modeling and control.
On the LIBERO benchmark, it performs the best among all publicly released methods that do not need a VLM to generate actions. Its size and performance sit on the reported Pareto frontier.

During inference, WorldDiT acts for a few steps, observes what changed, and replans. World modeling stays in training, while light-weight deployment remains action only.

We are releasing the paper, model checkpoints, a self contained inference runtime, and a LIBERO evaluator. You can find everything below.
📜 arxiv.org/abs/2607.23909
🤗 huggingface.co/bageldotcom/w…

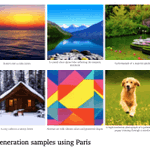
Today we're releasing Paris 2.0, to our knowledge the first decentralized-trained video generation model.
At Bagel Labs, we believe frontier models should not require homogeneous clusters of premium, supply constrained GPUs. Paris 1.0 proved this for image generation. Paris 2.0 extends the recipe to video generation and lays the substrate for global-scale world models.
To test the approach, we trained two models head-to-head in an iso-FLOP, iso-data comparison. One was a monolithic model trained conventionally, on a single premium GPU cluster. The other was Paris 2.0, trained across an extreme mix of GPU types, generations, and vendors distributed around the globe.
Against the monolithic model under matched data and compute, the results were:
FVD: 561.04 → 279.01 (a ~2x improvement)
CLIP text-video alignment and aesthetic score both improved.
To our knowledge, this is the first distributed training architecture to surpass its monolithic counterpart under matched data and compute.
Technical Report: arxiv.org/abs/2605.26064
Model Weights: huggingface.co/bageldotcom/p…

bagel.com retweeted
We're releasing Paris 2.0, which, to our knowledge, is the world's first decentralized trained video generation model.
We benchmarked it against a monolithic model trained on the same data and compute budget, and Paris 2.0 outperformed the monolithic by ~2x on FVD benchmark.

bagel.com retweeted

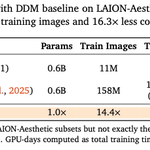
we managed to extend DDM to heterogeneous objectives! one step closer to decentralized AI XD
tldr: experts trained in complete isolation, with different objectives, no communication - and mixing them beats making them all train the same way. 20-48G memory per expert
Excited to share that Bagel Labs' paper got accepted at CVPR 2026.
A lot of the most important diffusion model research has historically stayed inside frontier labs. We're bringing more of that in the open through open science and open infrastructure.
In this work we showcase the very counterintuitive advantage of mixing different training objectives (DDPM and Flow-Matching) through an ensemble of diffusion models. This is one of the first ever works to successfully combine diffusion models trained with heterogeneous objectives.
See details here: blog.bagel.com/p/heterogeneo…
