
Founding Scientist @ Dexmate | exRS@FAIR | GaTech PhD
Joined September 2019
- Tweets61
- Following190
- Followers196
- Likes220




Tianyu Li EasyPaperSniper retweeted

We’re sharing a solution to the Navier-Stokes Millennium Prize Problem, one of the deepest problems at the frontier of mathematics.
The proof was produced by a group of agents, using an OpenAI next-generation model significantly more capable than GPT-6 Astra.
The problem concerns whether the description of smooth three-dimensional fluid motion modeled by the Navier-Stokes equations can break down. It has remained unresolved for roughly 90 years.


Tianyu Li EasyPaperSniper retweeted

We present EgoReAct: Real-time 3D human reaction generation from streaming egocentric video.
🌟Reacting to streaming egocentric video is something humans do every day. We hope EgoReAct makes human motion more human-like.
🔎 What we found: existing ego-reaction data can be spatially inconsistent (e.g., moving reactions paired with fixed-camera videos), which breaks 3D grounding.
📷 What we built: HRD, a spatially aligned egocentric video–reaction dataset (3,500 pairs, 32 categories), plus a spatially aligned ViMo fix for fair evaluation. (Instead of collecting expensive ground-truth motion, we employ VDM to generate the egocentric videos.)
👁️⚡🏃 Our simple yet effective pipeline: motion tokenization for compact discrete codes + an autoregressive Transformer for online, strictly-causal generation. Metric depth and head dynamics further improve 3D spatial consistency.
Project Page: frank-zy-dou.github.io/proje…
ArXiv: arxiv.org/abs/2512.22808
#HumanMotion #EgocentricVision #3D #ARVR #Animation #AIGC #DeepLearning #GenerativeAI #Graphics #ComputerVision #Motion – at Cambridge, MA

Tianyu Li EasyPaperSniper retweeted

Imagine moving a heavy object with a joystick—through a swarm of quadruped-arm robots.
🕹️ decPLM: decentralized RL for multi-robot pinch-lift-move.
• No comms or rigid links
• Hierarchical RL + constellation reward
• 2→ N robots, sim→real
🔗 decplm.github.io/
Tianyu Li EasyPaperSniper retweeted

Wrapping up @GeorgiaTech’s technical tours today, hosting visitors from @icra, with a sword wielding spot demo from @sehoonha and @SniperPaper. @gtcomputing


Tianyu Li EasyPaperSniper retweeted
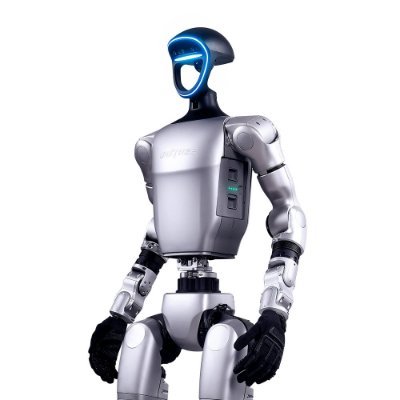
Unitree B2-W Talent Awakening! 🥳
One year after mass production kicked off, Unitree’s B2-W Industrial Wheel has been upgraded with more exciting capabilities.
Please always use robots safely and friendly.
#Unitree #Quadruped #Robotdog #Parkour #EmbodiedAI #IndustrialRobot #InspectionRobot #IntelligentRobot #FoundationModels #LeggedRobot #WheeledLegs
Tianyu Li EasyPaperSniper retweeted

It is just so sad that the #NeurIPS2024 main conference ended with such a racist remark by a faculty when talking about ethics. How ironic!
I also want to commend the Chinese student who spoke up right on spot. She was respectful, decent, and courageous. Her response was exemplary: she began by acknowledging the speaker’s efforts, then gave the speaker an opportunity to clarify (though, regrettably, the speaker’s reply only reinforced her bias), and ultimately called attention to the inappropriate racial bias and offered constructive suggestions. Thank you for speaking out!

Tianyu Li EasyPaperSniper retweeted
Our computer graphics faculty had some amazing research on display at @SIGGRAPHAsia in December, including @sehoonha's work on teaching human movement to quadrupedal robots.
youtu.be/zgiUY86MEEI?si=1qQb… via @YouTube
Tianyu Li EasyPaperSniper retweeted

Can human motion be transferred to robots? We present our recent #ICLR paper, CrossLoco, a novel guided unsupervised reinforcement learning algorithm to establish motion correspondence between humans and quadrupeds. @SniperPaper @HyunyoungJung5 @MatthewGombolay #ICLR2024
Tianyu Li EasyPaperSniper retweeted

Can GPTs generate infinite and diverse data for robotics?
Introducing RoboGen, a generative robotic agent that keeps proposing new tasks, creating corresponding environments and acquiring novel skills autonomously!
code: github.com/Genesis-Embodied-…
👇🧵
(better with audio)
Tianyu Li EasyPaperSniper retweeted

Announcing Habitat 3.0, simulating humanoid avatars and robots collaborating!
- Humanoid sim: diverse skinned avatars
- Human-in-the-loop control: mouse/keyboard or VR
- Tasks: social navigation and rearrangement
Over 1,000 steps per second on 1 GPU for large-scale learning!
Tianyu Li EasyPaperSniper retweeted

Didn't think this is possible but we made it! Glad to finish my master with this exciting project with amazing collaborators @teenhaci, @anag004 and @deepakpathak!

Even after 4yrs of locomotion research, we keep getting surprised by how far we can push the limits of legged robots! We report a major update 🚀🤖
Extreme Parkour: extremely long & high jumps, ramp, handstand, etc. all with a single neural net!
extreme-parkour.github.io/
🧵(1/n)
Tianyu Li EasyPaperSniper retweeted
Can we transfer human motions to characters with very different morphologies? I am happy to share our recent #SIGGRAPHAsia paper, Adversarial Correspondence Embedding (ACE), to retarget human motions onto various characters and robots. @SIGGRAPHAsia @SniperPaper @jeonghwankim0
Tianyu Li EasyPaperSniper retweeted

I'm very excited to share our super simple system for teaching robots complex tasks using existing controllers ◡̈ Building on our prior work, we've taught the A1 challenging skills like bipedal walking. We hope this general recipe simplifies training for all kinds of robots!

We've taught our robot dog new tricks! Our new transfer learning method, TWiRL, makes it possible to train highly agile tasks like jumping and walking on hind legs, and facilitates transfer across tasks and environments: sites.google.com/berkeley.ed…
Tianyu Li EasyPaperSniper retweeted
Our work, "Learning and Adapting Agile Locomotion Skills by Transferring Experience" (sites.google.com/berkeley.ed…) will be presented today at @RoboticsSciSys in Session 7. Mobile Manipulation and Locomotion. Congratulations again, @smithlaura1028 @svlevine @xbpeng4 @SniperPaper

Tianyu Li EasyPaperSniper retweeted

In addition to hardware such as DIGIT, developing touch sensing as a modality requires an ecosystem of touch processors, simulators, benchmarks & data sets. Read more about our ongoing work in developing & open-sourcing this ecosystem: ai.facebook.com/blog/teachin…

Tianyu Li EasyPaperSniper retweeted

We’ve acquired the MuJoCo physics simulator (mujoco.org) and are making it free for all, to support research everywhere. MuJoCo is a fast, powerful, easy-to-use, and soon to be open-source simulation tool, designed for robotics research: dpmd.ai/mujoco-blog