

Official account for OpenDriveLab @hkuniversity and Beyond. We do cutting-edge research in Robotics, Autonomous Driving. Email: [email protected]
Hong Kong
Joined June 2022
- Tweets241
- Following67
- Followers1.9K
- Likes279




OpenDriveLab retweeted

Check out Jin’s latest work on utilizing human data to unlock robot whole-body capabilities! #WBI #WholeBodyIntelligence opendrivelab.com/EgoHumanoid…

OpenDriveLab retweeted

Let's go Archon!!!!! 🤖

🤖 Building Whole-Body Intelligence for the Real World. Were Just Getting Started.
From bending down to pick up objects and navigating steps to autonomously clearing tables, operating dishwashers, and organizing refrigerators, our robots are learning to perceive, move, manipulate, and coordinate their entire bodies in real-world environments.
Powered by our Whole-Body Intelligence (WBI) framework, were building generalist humanoid foundation models by combining large-scale human whole-body data pretraining, context-aware behavioral foundation models, and efficient post-training with real-robot data - turning human experience into real-world robotic skills.
👉 Watch Whole-Body Intelligence in action in our three-minute demo. More to come. Stay tuned at archon.tech
#ArchonRobotics #WholeBodyIntelligence #WBI #Humanoid #PhysicalAGI
Proud to co-organize the AlpaSim E2E Closed-Loop Challenge with @kesai_labs and NVIDIA’s ASPIRE Group. This post traces the journey from NAVSIM to photorealistic closed-loop evaluation—and our shared effort to make progress in autonomous driving measurable. Learn more ↓

Making progress measurable in autonomous driving. Our new post traces the path from NAVSIM to the AlpaSim challenge: kesai.eu/blog/2026-09-08-com…

OpenDriveLab retweeted

Full episode dropping soon!
Geeking out with @idomihs on EgoHumanoid: Unlocking In-the-Wild Loco-Manipulation with Robot-Free Egocentric Demonstration opendrivelab.com/EgoHumanoid…
Co-hosted by @micoolcho @DJiafei
Huge shout-out to our amazing organizing team @2318hhhz @wongfaikit @lucy_x_shi @smch_1127 Yasemin_Bekiroglu @francislee2020 — this wouldn't have happened without you! 🙌
📺 Our workshop recap is now live: RSS 2026 | Towards Robust Execution of Long-Horizon Whole-Body Control Tasks
Catch the full playlist here 👇
youtube.com/playlist?list=PL… from @YouTube
#rss226 #WholeBodyIntelligence #embodiedAI

OpenDriveLab retweeted

🚀 Excited to announce our real world VLN dataset !
📦 Human first-person collected indoor & outdoor & night.
🏆 LARGEST to date.
Check it out now on Hugging Face and accelerate your real world navigation research!
👇 🔗 huggingface.co/datasets/Open…
#EmbodiedAI #VLN

Sydney-bound for #RSS2026, and not gonna lie, we’re buzzing! 🔥
On our slate:
OpenDriveLab.com/rss2026/
🎤 Dr. Hongyang Li — Early Career Spotlight
📄 Two papers we're proud of: RISE & EgoHumanoid
🤖 A humanoid doing real work on the floor - July 13th Morning Workshop
Full rundown + where to find us 👇
medium.com/@opendrivelab/ope…
Come have a yarn.
#EmbodiedAI #WholebodyIntelligence #VLA #WorldModels #Sydney #ICC – at Sydney, New South Wales


Sydney, come sundown. 🌃
OpenDriveLab x @archon_robotics are throwing an afterparty!
TopTalents for Embodied AI, a social mixer at W Sydney, harbour views, golden hour, and the people building the next gen of Embodied Intelligence.
📅 Jul 14 · 7–10PM
📍 W Sydney
🎟️ Apply: luma.com/0ml7kuwb
#RSS2026 #EmbodiedAI #Sydney #WorldModel #FoundationModel

Sydney, come sundown. 🌃
OpenDriveLab x @archon_robotics are throwing an afterparty!
TopTalents for Embodied AI, a social mixer at W Sydney, harbour views, golden hour, and the people building the next gen of Embodied Intelligence.
📅 Jul 14 · 7–10PM
📍 W Sydney
🎟️ Apply: luma.com/0ml7kuwb
#RSS2026 #EmbodiedAI #Sydney #WorldModel #FoundationModel – at Sydney, New South Wales
🚀 Join us at the #CVPR 2026 Workshop:
From Labs to Life: Embodied Intelligence in the Wild
(opendrivelab.com/cvpr2026/wo…)
As embodied AI moves into the real world, we ask: how can agents perceive, reason, and act reliably in the wild?
Featuring invited talks from: Hao Su, Zhiyu Huang, Jiahui Lei, Yilun Du, Rika Antonova, Jiatao Gu.
📅 9:00 AM - 5:30 PM, June 3, 2026
📍 Four Seasons 1, Colorado Convention Center.
#CVPR #EmbodiedAI #PhysicalAI #Robotics


OpenDriveLab retweeted

SimScale is fully open-sourced!!!
📄 arXiv: arxiv.org/abs/2511.23369
💻 Code: github.com/OpenDriveLab/SimS…
🤗 Ckpts + Sim Data: huggingface.co/datasets/Open…

OpenDriveLab retweeted
🎉 Excited to share our recent work SimScale, which has been accepted to CVPR 2026 as Oral presentation!
🤖Can we improve policies via scaling synthetic experience?
😢End-to-end driving policies struggles on safety-critical & OOD scenarios that are rare in human logs.
To tackle this, SimScale features:
🏗️ A scalable simulation pipeline synthesizes diverse, high-fidelity reactive driving scenarios upon existing logs. (See attached visualization as one synthetic data sample).
🚀 With pseudo-expert demonstrations, Sim-real co-training boosts LTF / DiffusionDrive / GTRS-Dense, up to +8.6 EPDMS on navhard, +2.9 on navtest.
🔬 Performance scales smoothly by adding simulation data alone, with no extra real-world data needed.
Joint effort by @HCTian713, @francislee2020, @OpenDriveLab, @sephy_li
📢📢📢 Call for Contributions @ RSS 2026
Towards Robust Execution of Long-Horizon Whole-Body Control Tasks
🧑💻👩💻🧑💻 Speakers:
- Javier Alonso-Mora (TU Delft)
- Leslie Pack Kaelbling (MIT)
- Shan Luo (King's College London)
- Hamidreza Kasaei (University of Groningen)
- Roberto Martín-Martín (UT Austin)
- Fan Shi (NUS)
📝📝📝 Call for Contributions:
We invite researchers to share their work with the community through submissions to the workshop in a variety of formats beyond traditional papers, including reports, demos, video, and etc. Submissions may include research papers or reports, but we equally welcome alternative formats such as videos demonstrating systems in action, demos, interactive artifacts, or other creative presentations of research ideas. We particularly welcome ongoing, preliminary, or exploratory work.
🌍🌍🌍 Website:
opendrivelab.com/rss2026/wor…
#RSS2026 #AI #Embodied

OpenDriveLab retweeted
🤗RISE got accepted to RSS 2026! Can't wait to see everybody in Sydney!
💻Code: github.com/OpenDriveLab/RISE


RISE (3/N)
To address this bottleneck, we introduce RISE: Reinforcement learning via Imagination for SElf-improving robots. RISE shifts the learning environment from physical world to a Compositional World Model, which first emulates future observations for proposed actions, then evaluates imagined states to derive advantage for policy improvement.

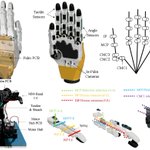
🚀 MM-Hand 1.0 Tech Report released: a 21-DoF multi-modal modular dexterous robotic hand with remote tendon-driven actuation.
Motors are relocated outside the hand, freeing space for tactile sensors, joint encoders, in-palm stereo vision, and maintainable modular fingers.
MM-Hand achieves 25N fingertip force through 1m tendon-sheath transmission and supports closed-loop joint control for dexterous manipulation research.
Paper: arxiv.org/abs/2604.17245
Page: opendrivelab.com/MM-Hand
#Robotics #DexterousHand #EmbodiedAI

OpenDriveLab retweeted
🌏 RISE is now open-sourced!
github.com/OpenDriveLab/RISE
🧐Applying world models to improve real-world policy on challenging manipulation tasks used to be considered out of reach.
😌After sustained effort, we’re now seeing encouraging progress.
🚀Thrilled to introduce RISE: Self-Improving Robot Policy with Compositional World Model
opendrivelab.com/kai0-rl/
arxiv.org/abs/2602.11075
RISE is, to our knowledge, the first work to use a world model as an effective learning environment for challenging real-world manipulation, enabling policy improvement on tasks that demand high dynamics, dexterity, and precision.
Incredible teamwork with @lin_kunyang111 @francislee2020 @YueXiangyu @HaoZhao_AIRSUN @smch_1127

【5/5】That's all!
Hope #WorldEngine brings you fresh insights into post-training infrastructure for Physical AI.
If you find it useful, please give it a star 🌟!
Github: github.com/OpenDriveLab/Worl…
Huggingface: huggingface.co/datasets/Open…
Project Page: opendrivelab.com/WorldEngine…
Teamwork from @OpenDriveLab
Shoutout to @sephy_li @ilnehc @francislee2020 @CaojunWang @GeorgeL94133026 📢

【3/5】📺Visualization
① Our Behaviour World Model seeds from real-world cases to synthesize what your dataset is missing — cut-ins, sudden braking, edge-case interactions at scale.
② Post-training with World Engine: before vs. after.
③/④ The post-trained E2E model deployed in WorldEngine.


【2/5】🎉Highlights
- Data-driven long-tail discovery: Failure-prone scenarios are automatically identified from real-world driving logs by the pre-trained agent itself — no manual design, no synthetic perturbations.
Photorealistic interactive simulation via 3DGS: Each discovered scenario is reconstructed into a fully controllable, real-time-renderable simulation environment with independent dynamic agent manipulation.
- Behavior-driven scenario generation: Leverages Behavior World Model (BWM) to generalize and synthesize diverse traffic variations from existing long-tail scenarios, expanding sparse safety-critical events into a dense, learnable distribution.
- RL-based post-training on synthesized safety-critical rollouts substantially outperforms scaling pre-training data alone — competitive with a ~10× increase in pre-training data.
- Production-scale validation: Deployed on a mass-produced ADAS platform trained on 80,000+ hours of real-world driving logs, reducing simulated collision rate by up to 45.5% and achieving zero disengagements in a 200 km on-road test.
