@ybisk most places -- Prof @SCSatCMU and building stuff with https://xitter.cf/t.co/U0b5mUU7gX @origami_robotic

Pittsburgh, PA
Joined March 2009
Dear #AcademicTwitter: This is a friendly reminder that you're people first and researchers second. Taking mental health days is completely legit. The bar to take time is not an election/earthquake/court ruling... you are always entitled to protect your mental health.
1
5
3
91
Dexterity reimagined.
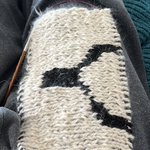
Discovering dexterity: At home with my infant, and at Origami @origami_robotic ... More tomorrow 👀
3
9
1
20
823
Discovering dexterity: At home with my infant, and at Origami @origami_robotic ... More tomorrow 👀
16
24
12
133
29,998
Yonatan Bisk retweeted
I am at #COLM2026 this week in SF: > presenting a paper on reasoning behaviors in language models with @Jeande_d, @ybisk, @gneubig on Thursday (more info in thread below) > co-organizing the Workshop on Learning from Situated and Embodied Interaction on Friday 🤖 (learning-situated-interactio…) Excited to hear about everyone's research and happy to chat about work that I have been doing on multimodal social intelligence in AI agents across embodiments!
8
8
46
1,902
🧵New Paper: Reasoning models now think out loud for thousands of tokens, often correcting themselves, testing hypotheses, and hedging. But are these behaviors actually associated with correct answers? Largely, no. Looking at accuracy, these models are doing great and often outperform their instruct counterparts. But accuracy does not tell the whole story. It does not tell us which behaviors showed up in the trace, which failures happened along the way, or whether the behaviors thinking amplifies are the ones most associated with correctness. In our new paper, we study whether thinking models amplify the reasoning behaviors most associated with correct answers. This is important because a behavior can become more frequent without being a sign that the answer is right. For a quick example, a model may branch over several hypotheses without testing the right one, or revise its wording without fixing the reasoning underneath. We introduce Behavioral Lift, which measures how much correctness differs when a behavior is present versus absent. Across 15,282 annotated traces from 15 models on 6 reasoning and knowledge benchmarks, we find a consistent mismatch. Thinking models strongly amplify self-correction, hypothesis testing, and uncertainty acknowledgment. But the highest-Lift behaviors change much less: confidence calibration, self-awareness, and knowledge alignment. We call this the Amplification-Lift Gap. The attached figure shows the gap: no behavior is both strongly amplified and strongly predictive of task success. ArXiv: arxiv.org/abs/2608.13760 Work with an amazing team: @Jeande_d, @lmathur_ , @ybisk, Robert Hawkins, @gneubig
7
21
4
98
22,814
Yonatan Bisk retweeted
Diffusion / flow-based robot policies unlock two axes of test-time scaling: sequential (denoising steps) and parallel (samples). Both improve performance but cost latency on a robot, and knowing which to scale a priori is often unclear. ELASTIC learns it via RL!
4
20
3
96
25,316
Yonatan Bisk retweeted
Inductive Generalization for Robotic Manipulation Annabella Macaluso, Haochen Zhang, Ishaan Masilamony, Yingshan Chang, Yonatan Bisk arxiv.org/abs/2606.20999 [𝚌𝚜.𝚁𝙾 𝚌𝚜.𝙻𝙶]
2
3
321
This fall semester, I will be moving my GLAMOR lab (glamor.rocks/) to the School of Interactive Computing (IC) at the Georgia Institute of Technology!
11
10
2
152
19,734
Yonatan Bisk retweeted
🤖 What would LMArena for robotics look like? Introducing RobotArena ∞ We turn real videos into simulated environments and evaluate robot policies at scale using VLM scoring + human preferences A scalable benchmark for robot generalists 🔗 robotarenainf.github.io/ Details 🧵👇
5
27
5
125
22,647
Yonatan Bisk retweeted
Origami Robotics is building high-DOF robotic hands with in-joint motors and a co-designed data-collection glove to eliminate the embodiment gap by collecting high-quality, real-world data at scale. Congrats on the launch, @DanielXieee and @QuanliangX! ycombinator.com/launches/Pcl…
27
40
19
295
90,235
Yonatan Bisk retweeted
These guys get it (equally true for rest of robot, for safety and ability to learn thru failure, not just sim2real gap) Adding NEOs hands: DOF: 22 (44 active tendons per hand, fully actuated) Ratio: 8:1 (w/tendons, 1X custom high-torque motors) Sim2Real Gap: Low (10-15% friction, high stiffness) Force Transparency: High (motor currents) Reliability: High (3.5m cycles at nominal load)
Why does manipulation lag so far behind locomotion? New post on one piece we don't talk about enough: The gearbox. The Gap You've probably seen those dancing humanoid robots from Chinese New Year. Locomotion isn't entirely solved; but clearly it's on a trajectory. But we haven't seen anything close for manipulation. 𝗪𝗵𝘆? When sim-to-real transfer fails, the instinct is to blame the algorithm. Train bigger networks. Crank up domain randomization. Those approaches have made real progress; we don't deny that. But we started wondering: are we treating the symptom or the disease? The Hardware Bottleneck: Fingers are too small for powerful motors. So most hands use massive gearboxes (200:1, 288:1) to get enough torque. But those gearboxes break everything manipulation needs:   • Stiction and backlash are complex to simulate. Policies trained on smooth physics hallucinate when they hit that reality.   • Reflected inertia scales as N². At large gear ratio, the finger hits with sledgehammer momentum.   • Friction blocks force information. The hand becomes blind. And they're the first thing to break. What we are trying to build at Origami, we cut the gear ratio from 288:1 to 15:1 using axial flux motors and thermal optimization. The transmission becomes more transparent: backdrivable, low friction, forces propagate to motor current. Early signs are encouraging. Still running quantitative benchmarks. Why Interactive? I love how Science Center uses interactive devices to explain complex ideas. I want to borrow this concept and help people understand the hard problems in robotics better visually. The post has demos where you can toggle friction, slide gear ratios, watch the sim-to-real gap widen in real-time. What's inside:   • Interactive demos (friction curves, N² scaling, contact patterns)   • Comparison table: 14 robot hands by sim-to-real gap and force transparency   • The math behind why low-ratio matters Read it here: origami-robotics.com/blog/de… We're not claiming we've solved dexterity. The deadlock has many pieces. But we think this one's foundational. Curious what you think.
10
27
6
226
64,557
Yonatan Bisk retweeted
Very insightful points on the Sim2Real gap for manipulation vs locomotion.
Why does manipulation lag so far behind locomotion? New post on one piece we don't talk about enough: The gearbox. The Gap You've probably seen those dancing humanoid robots from Chinese New Year. Locomotion isn't entirely solved; but clearly it's on a trajectory. But we haven't seen anything close for manipulation. 𝗪𝗵𝘆? When sim-to-real transfer fails, the instinct is to blame the algorithm. Train bigger networks. Crank up domain randomization. Those approaches have made real progress; we don't deny that. But we started wondering: are we treating the symptom or the disease? The Hardware Bottleneck: Fingers are too small for powerful motors. So most hands use massive gearboxes (200:1, 288:1) to get enough torque. But those gearboxes break everything manipulation needs:   • Stiction and backlash are complex to simulate. Policies trained on smooth physics hallucinate when they hit that reality.   • Reflected inertia scales as N². At large gear ratio, the finger hits with sledgehammer momentum.   • Friction blocks force information. The hand becomes blind. And they're the first thing to break. What we are trying to build at Origami, we cut the gear ratio from 288:1 to 15:1 using axial flux motors and thermal optimization. The transmission becomes more transparent: backdrivable, low friction, forces propagate to motor current. Early signs are encouraging. Still running quantitative benchmarks. Why Interactive? I love how Science Center uses interactive devices to explain complex ideas. I want to borrow this concept and help people understand the hard problems in robotics better visually. The post has demos where you can toggle friction, slide gear ratios, watch the sim-to-real gap widen in real-time. What's inside:   • Interactive demos (friction curves, N² scaling, contact patterns)   • Comparison table: 14 robot hands by sim-to-real gap and force transparency   • The math behind why low-ratio matters Read it here: origami-robotics.com/blog/de… We're not claiming we've solved dexterity. The deadlock has many pieces. But we think this one's foundational. Curious what you think.
1
6
64
9,448
Yonatan Bisk retweeted
Why does manipulation lag so far behind locomotion? New post on one piece we don't talk about enough: The gearbox. The Gap You've probably seen those dancing humanoid robots from Chinese New Year. Locomotion isn't entirely solved; but clearly it's on a trajectory. But we haven't seen anything close for manipulation. 𝗪𝗵𝘆? When sim-to-real transfer fails, the instinct is to blame the algorithm. Train bigger networks. Crank up domain randomization. Those approaches have made real progress; we don't deny that. But we started wondering: are we treating the symptom or the disease? The Hardware Bottleneck: Fingers are too small for powerful motors. So most hands use massive gearboxes (200:1, 288:1) to get enough torque. But those gearboxes break everything manipulation needs:   • Stiction and backlash are complex to simulate. Policies trained on smooth physics hallucinate when they hit that reality.   • Reflected inertia scales as N². At large gear ratio, the finger hits with sledgehammer momentum.   • Friction blocks force information. The hand becomes blind. And they're the first thing to break. What we are trying to build at Origami, we cut the gear ratio from 288:1 to 15:1 using axial flux motors and thermal optimization. The transmission becomes more transparent: backdrivable, low friction, forces propagate to motor current. Early signs are encouraging. Still running quantitative benchmarks. Why Interactive? I love how Science Center uses interactive devices to explain complex ideas. I want to borrow this concept and help people understand the hard problems in robotics better visually. The post has demos where you can toggle friction, slide gear ratios, watch the sim-to-real gap widen in real-time. What's inside:   • Interactive demos (friction curves, N² scaling, contact patterns)   • Comparison table: 14 robot hands by sim-to-real gap and force transparency   • The math behind why low-ratio matters Read it here: origami-robotics.com/blog/de… We're not claiming we've solved dexterity. The deadlock has many pieces. But we think this one's foundational. Curious what you think.
24
99
38
657
152,496
Yonatan Bisk retweeted
I'm excited to share that RAVEN was accepted to ICRA 2026! Paper: arxiv.org/abs/2509.23563 Website: raven-semantic.github.io Collaboration with @OmarAlama, Dmytro Kurdydyk, John Keller, @Nik__V__ , Wenshan Wang, @ybisk , @smash0190 See you in Vienna!
We introduce RAVEN, a 3D open-set memory-based behavior tree framework for aerial outdoor semantic navigation. RAVEN not only navigates reliably toward detected targets, but also performs long-range semantic reasoning and LVLM-guided informed search
1
8
27
3,248
🚀Apply to CMU LTI’s Summer 2026 “Language Technology for All” internship🎓Open to pre‑doctoral students new to language tech (non‑CS backgrounds welcome). 🔬12-14 weeks in‑person in Pittsburgh; travel + stipend paid.💸Deadline: Feb 20, 11:59pm ET. forms.gle/cUu8g6wb27HsWWkd7
8
85
4
595
85,402
Yonatan Bisk retweeted
A few days ago we got in YC W26, and here is we are working on. Building hardware is hard, but I really like a quote from @yukez: “People who are really serious about robot learning should make their own robot hardware.”
96
134
13
1,293
126,756
Our paper has been accepted to IEEE RA-L! 📝 "Affordance RAG: Hierarchical Multimodal Retrieval with Affordance-Aware Embodied Memory for Mobile Manipulation" 🔗 arxiv.org/abs/2512.18987 This work was done during my stay at @LTIatCMU as part of the Keio-CMU Research Partnership.
11
2
46
9,617
Yonatan Bisk retweeted
I'm co-organizing a new 🏙️ Workshop on Agentic AI Benchmarks and Applications for Enterprise Tasks 🏙️ together with collaborators at Fujitsu! As agents move towards the real world, we need more rigorous research work on this topic.
3
8
131
10,660
Yonatan Bisk retweeted
Andrea Bajcsy (@andrea_bajcsy) on from refusal to recovery (a lot of cool demos) -- in some scenarios, it's important to recover than to refuse -- deployment-time gaurdrails through safety filters (not handcoded but computed ) -- safety filters: a safety policy learned from failure states. Kicks in as soon as base generative policy is closer to failure states -- notion of failure shouldn't be limited to known failure states but also epistemic uncertainty -- safety is also context dependent. This is where LLMs are helpful. Translate latent state trajectories into language. And steer policy to safe behavior modes.
3
9
2,636
Yonatan Bisk retweeted
Yonatan Bisk (@ybisk) on Spatial and Semantic Awareness in Embodied LMs -- Abstract underspecified questions for meaningful exploration of environment. Helps when to build a concept. -- VLMs need to understand trajectories, but are currently bad at these. Understanding time is critical. -- even tools aren't helpful -- Robots are great to explore all these questions -- completeness and coverage are two dimensions to build models that genearlize
2
20
2,860
Yonatan Bisk retweeted
I am feeling incredibly grateful🙏 as I share two big milestones. At @CarnegieMellon, I've been exploring robotics, AI, and human communication. This journey challenged me to grow, reminded me there is always more to learn, and brought amazing people into my life. A few weeks ago, I defended my PhD thesis. 🎓 This wouldn’t have been possible without my advisor, @ybisk, who believed in me even when I didn’t. I’m also thankful to my committee for their research vision and guidance. To my friends, and family - for celebrating my small wins and for lifting me up through the challenges. Now, as one chapter closes, another begins! I am beyond excited to join @OpenAI to continue building AI systems that better understand and work with people. Looking forward to staying curious, collaborating, and creating impact in what comes next.🚀
73
29
6
1,158
90,822