




Howdy, Austin! 🤠 Sudo is heading to CoRL 2026!
We’re mixing simulation and real-world data to teach our robot new skills, and we can’t wait to show you what it’s learned. Proud to be a patron sponsor!
Swing by booth 202 to meet the team and see it live.
📅 Nov 9–12 📍 Austin, TX #CoRL2026 #robotics #robotlearning

🔷 Thanks to @sudo_robotics for being a Patron Sponsor of #CoRL2026! 🤖
🛠️ Building general-purpose robots, skill by skill
Pick. Place. Pack. Insert. Assemble.
Trained in sim. Built to generalize.
Great to put our robot’s latest skills on show in Santa Clara last weekend at #alignment2026. Thanks to everyone who stopped by our booth to watch it in action!
@Valley101en


Out of office: our robot has weekend plans. 🤖
Catch us at #Alignment2026, Valley 101’s Annual Tech Summit, for live demos. Bring your toughest pick-up requests to Booth C5 and put our robot to the test.
📅 Oct 10–11 · 9am–5pm
📍 Booth C5 · Plug and Play Tech Center, Sunnyvale, CA

Our first public event in Zurich came with an open invitation: bring any item you have with you and challenge our robot.
Our robot had never seen these items before. It was trained entirely in simulation, with no real-world training data, and handled them all.
A demo with prepared objects is not the hard part anymore. The hard part is what happens when a robot meets something nobody prepared it for.
#robotics #robotlearning #zurich
At the upcoming IROS 2026 conference in Pittsburgh, sudo joins the keynote plenary panel: from research to company, what does it really take?
→ What does it take to turn promising research into a product that solves a real problem?
→ What evidence do investors need to back that transition?
→ How do you build a company around the technology, scale, and grow internationally?
At sudo, we're building a platform that helps developers create robotics applications for factories, warehouses, and homes — not just demos. Looking forward to exchanging perspectives on what it takes to bring robotics out of the lab and into everyday use.

Sudo is excited to demo our robot live at the DARE Campus Robot Showcase, Zurich AI Festival, 30 Sept! 🤖 Come see our first Zurich demo open to the public.
📍 The JED, Zurich-Schlieren
Register: luma.com/DAREcampusRobotShow…

We’re live at the Davos Tech Summit 🇨🇭
And we’re doing the most honest demo we know how to give.
The sudo R1 Challenge
📅 14:00–18:00
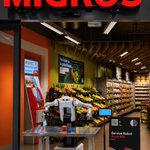
📍 Robot City Davos, inside Migros (Symondpark, Promenade 105)
Pick any item and watch R1 grab it, zero-shot. It has never seen these products before. Neither have we. Win prizes if you stump it.
“How to Solve the Robot Data Problem with Real2Sim2Real”
📅 July 2nd · 11:00–11:30, Technology Stage
Come break our robot 🛒
#sudo #R1Challenge #DavosTechSummit #robotics

Sudo AI retweeted

Zero-shot pick-and-place trained entirely in simulation! 👾
@sudo_robotics held their first public demo showing a mobile humanoid robot doing zero-shot pick-and-place at ICRA.
The robot foundation model was trained entirely in simulation, no real-world data, no teleoperation.
Pick and place is the fundamental skill. Until you solve it for any item, even items the robot has never seen, you won't solve downstream robotics problems.
Let’s have a look at the design: Mobile base with vertical mobility (Z-axis), seven degrees of freedom per arm, three RGB cameras (wrists + eyes). Two-finger gripper in this demo but gripper-agnostic for different use cases.
Trained under diverse lighting scenarios. Picks up anything. Audience members tested it with items from their pockets, keys, wallets, whatever. It has picked up straws and even my AirPods case 😁
For now this is a platform for developers and researchers. Demo centers opening in Shanghai, Zurich, and Mountain View.
~~
♻️ Join the weekly robotics newsletter, and never miss any news → ziegler.substack.com
We’re live at Booth 638 at CVPR. Come test the robot yourself and see how simulation is helping unlock more capable, general-purpose robotic systems.

A first look at what we’re building at Sudo AI. Introducing #sudo R1.
We train robots entirely in simulation, then deploy them directly to hardware - no data collection, per-object tuning, or calibration.
In this first release shared in our blog, #sudo R1 runs 60 minutes uncut and reliably picks objects it has never seen before: glass, fabric, metal, irregular shapes - under changing lighting, clutter, and physical interference.
Simulation-trained systems rarely hold up in practice. We think that’s starting to change.
If you’re building in robotics or thinking about where this is going, follow along at sudo.ai