
We are the Soft Robotics Group of @KU_Leuven
Leuven
Joined July 2020
- Tweets23
- Following153
- Followers543
- Likes52




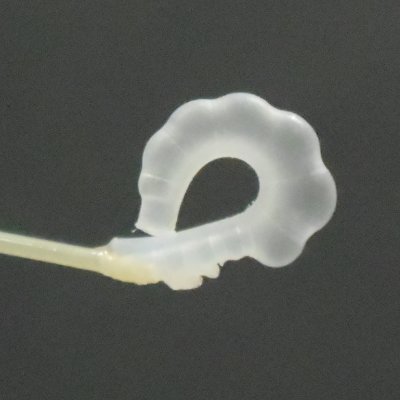
In one month we are hosting students from the ATHENS university network, and submerge them in an intensive short-duration course, to become soft robotic experts in one week. To kickstart their soft robotic journey, we send them a DIY soft robotic package at home! Exciting times!

Come join our lab!

Just a few more days until we close the job openings for 2 PhD students in the field of soft robotics @robotics_soft @KU_Leuven!
kuleuven.be/personeel/jobsit…
kuleuven.be/personeel/jobsit…
7
1,416
The lab is expanding! We are looking for 2 PhD to transform the field of soft robotics. Lots of cool research up ahead! – at Paradise, NV
In the framework of my @ERC_Research starting grant (ILUMIS), I am looking for 2 PhDs. Both will be transforming the field of soft robotics by harnessing nonlinearities in a fluidic network, one focusing on interconnections, the other on fluids.
Interested? See links bellow
Did you know that soft robots make excellent xmas tree decorations? The soft robotics research group of @KU_Leuven wishes you all a merry everything and a happy always.
Throwback to last week’s @robosoft22 conference. We had an absolutely amazing time with @BenjaminGoriss1 @edomil, Bert Van Raemdonck and David Mélançon. #robosoft22 – at Edinburgh, Scotland

@robosoft22 has officially started. Ready for a great week in Edinburgh. #robosoft2022

congrats to our @BenjaminGoriss1 @edomil @KU_Leuven and all co-authors from @CornellBME @hseas @MPI_IS @vermontUNI @Cambridge_Uni and more!
New paper out in today discussing the concept of embodied energy in robotics. We're hoping this perspective piece stirs up meaningful discussion and leads to a paradigm shift in how we design robots for autonomy. nature.com/articles/s41586-0…
@edomil @Nature

new paper out! 🤖

New Research: Morphological Control of Cilia-Inspired Asymmetric Movements Using Nonlinear Soft Inflatable Actuators: Soft robotic systems typically follow conventional control schemes, where actuators are supplied with dedicated inputs… frontiersin.org/articles/10.… #Robotics #AI
2
“Model-based control can improve the performance of artificial cilia”. Don’t miss the poster session later today at 4:30pm (Eastern Time) at #robosoft2021 ! @CosimoDella @edomil
We built an array of artificial cilia that mimics the individual and collective nonreciprocal motions of biological cilia using miniaturized soft inflatable actuators.
This Post is from an account that no longer exists. Learn more
