

Co-Founder & Lead Engineer at Trinity Labs LTD
Leeds, UK
Joined June 2018
- Tweets2.3K
- Following398
- Followers758
- Likes3.2K




Pinned Tweet
First test of @Raspberry_Pi controlled legs helping brake and accelerate @RoboMABEL. No driving here - only changes in centre of mass by moving the legs. Long way to go but at least I've got a test bed.
Since last summer I’ve been slowly learning the ropes on #kicad for my first ever audio hardware product. Can’t wait for 10.0 to drop, I’m especially looking forward to the hierarchical PCB design blocks so I can reuse parts of my design in other projects!


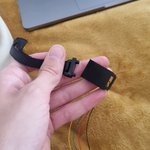
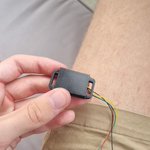
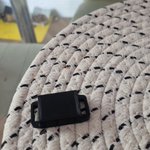
'fake' breakaway buckle design using magnets and empty cavity to house GPS. This has two benefits:
1. Distributes weight and components around collar allowing smaller profile
2. Can sit on top of neck allowing for sky line of sight for better signal.

Printed out a test enclosure for my cat tracking project, it's a little bulky which means I might not be able to do the OLED screen as a name tag as I planned. Going to move the GPS module onto the top of the collar and have the battery/microcontroller stuff at the bottom.

So Pleased to announce I have been accepted to study mechatronics and robotics at the university of Leeds! #AlevelResultsDay2022 A*AA!


Borrowed some animations and code from @adafruit for the catGPS interface. The refresh lines aren't visible to the human seeing balls don't worry.


Spend 2 hours wondering why QT py wasn't outputting any data to serial monitor, example code uses serial1 bus, when it should use serial0 as USB is native on esp32. One letter changed and now it seems to be more cooperative, now time to see if I get can the GPS to work.

Trying to figure out optimal layout for GPScat, modifications to the PCBs will need to be made. Planning to chop the charger board in half where the switch is and hard wire it to be on, so the gps module can sit where the switch is.
