




Pinned Tweet
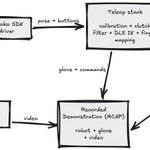
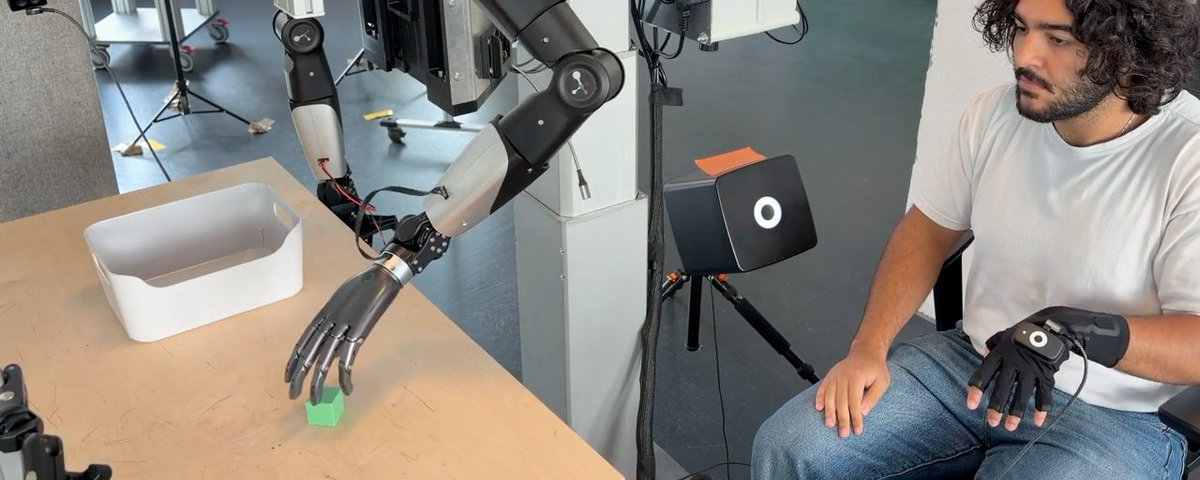
I built a teleop stack that lets me control a robot arm with mocap gloves
if you're curious about how it works: parsam.io/gloves/
I ended up using it to collect 221 robot demonstrations. the difficult parts were tracking the glove in space, mapping it onto a clanker, and keeping everything stable enough to collect useful data
Once it worked well enough, I used it to collect 99 demonstrations of picking up a cube and placing it inside a box.
The “dataset” contains ~28 minutes of robot motion. Collecting them took around an hour once you include resetting the cube and failed attempts.
Teleoperating also got noticeably easier as I continued. During the first quarter of one session, 73.5% of the control ticks were clean (the controller didn’t freeze the arm) and the median IK error was 93mm. By the last quarter, those numbers were 99.3% and 1.3mm. I was getting much better at knowing where its limits were and when to use the clutch.
I had some teammates who’d never done teleoperation before try it and they even managed to contribute to the robot data.
I later used it to collect another 122 robot demonstrations, bringing the total to 221 unique demonstrations. By then teleoperating felt much more natural, and I was getting surprisingly good at performing tasks with the robot.
Remember though, this still isn’t the original goal of having people perform work naturally by wearing the gloves. I’m still directly controlling a robot here, with a Coil sitting beside it and a calibration specific to that setup.
But it proved that the mapping worked well enough on physical hardware to collect useful robot data. I’ve since trained a policy on some of the data and got the robot to perform the task on its own, but that part deserves another post.
I plan to open-source the reusable parts of the teleoperation stack once I’ve cleaned them up and worked through the release details. If you want to know when that happens, you can follow me here or subscribe to my newsletter: parsam.substack.com/subscrib…

if you're curious how this works
xitter.cf/pzrsaa/status/20948544…


parsa retweeted

Building autonomy for one embodiment used to take years, now imagine doing it for dozens.
Pairing Yaak’s embodiment-agnostic hardware and Nutron (our data platform) with copper-rs (the Physical AI OS) lets us build intelligent machines as fast as software.
One stack. Any embodiment.
How Copper is accelerating our path to safe and scalable autonomy: yaak.ai/blog/yaak-x-copper
I've taken over the @Yaak_AI account, what do people want to see related to robotics?

Intelligence for the physical world has to come from the physical world.
We built a Spatial Intelligence Kit that pairs with any forklift, pallet jack, loader or sweeper in a few hours.
Full thesis → yaak.ai/blog/pair-learn-auto…
parsa retweeted
Intelligence for the physical world has to come from the physical world.
We built a Spatial Intelligence Kit that pairs with any forklift, pallet jack, loader or sweeper in a few hours.
Full thesis → yaak.ai/blog/pair-learn-auto…


