
PhD student @Cornell | Building caregiving robots @EmPRISELab | Prev: @ToyotaResearch @uwcse @IITKgp
Ithaca, NY
Joined November 2015
- Tweets353
- Following528
- Followers716
- Likes2.1K



Pinned Tweet
🤖 Robots are usually taught to avoid contact unless it’s at the end effector. But caring for a person, such as rolling them over or repositioning a limb, requires embracing contact along the entire arm. How do we enable robots to perform such contact-rich tasks?
Introducing TACTIC: Tactile and Vision Conditioned Contact-Centric Control for Whole-Arm Manipulation.
#RSS2026 🧵👇
Rishabh Madan retweeted

⚡️ High torque for acceleration, high speed after switching.
At #IROS2026, we’ll present trajectory optimization for humanoid motion exploiting our Variable Chain Motor, which switches its speed–torque characteristics on the fly.

Rishabh Madan retweeted

Yes, robotics is similar to computer use. This is why on a computer:
1) If you wrongly click a button you have to search for it in the jumble of the collapsed menu.
2) You click some buttons extra carefully because they might break.
3) You pull on the scrollbar carefully because if you pull too hard the whole app might come with it.
...so many other similarities ! 😇

I agree with Phil's take here: The progress of LLMs on controlling robots is quite interesting. Intuitively, this makes sense: controlling a robot is not so different from computer use, and an agent that is good at computer use is probably also good at controlling a robot and vice versa - credit to my student @RyuHyunwoooo to pointing that out to me originally!
Rishabh Madan retweeted

My group at Johns Hopkins now has a name and a website
Introducing the Brains, Bots, and Behavior Lab
b3.cs.jhu.edu
We're always looking for creative researchers at all levels to join us!

Rishabh Madan retweeted

Genuinely amazing how much better this looks than it used to though

They own the track and the high bar, but the penalty box still belongs to the humans, at least for sometime.
posture control after contact is such a hard problem.
Autonomous 5v5 soccer is underway at the World Humanoid Robot Games, with the machines recovering from falls more often than earlier trials but still far from controlled possession.
Rishabh Madan retweeted

Introducing GEN-1.5, a one-shot learner.
It can learn new tasks in a few seconds. Show it what to do, and it generalizes.
This capability emerged from pretraining on physical data at scale, as a step towards our mission of building general intelligence for the physical world.
Rishabh Madan retweeted

Super excited to share Dyna-2, the first robot foundation model trained on over 1 million hours of human data. At this scale, we saw the emergence of a cross-embodiment transfer scaling law: training on increasing amount of human data not only improves model prediction on held-out human data but also on robot data the model has never seen before 🤯
We validate that this transfer scaling law does translate to on-robot performance across 3 different robot platforms, and uncovers that both training objective and data matter greatly for this emergence. Crucially, our results position video as a new scaling axis for physical AI.
Beyond these scaling-law oriented results, we also dissect Dyna-2 greatly, going in-depth on its many capabilities, including language following via world modeling, enhanced robustness and precision, zero-shot customer site deployment, and some cool video generation results!
Read our technical blog post for more details! I do think this is a very important result that shows a very different path for robot foundation models from the ones we are marching on. Really excited for the road ahead. We have more releases coming, stay tuned!
Rishabh Madan retweeted

Today, @TactaSystems is unveiling our technology for the first time.
We are pioneering dexterous intelligence for robots.
Rishabh Madan retweeted

Can robots learn contact-rich tool use, like operating a pair of scissors✂️ or turning a screwdriver🪛, from human data?
Introducing REGRIND: a minimalist retargeting-guided RL recipe for dexterous manipulation.
🌐 yunhaifeng.com/REGRIND/
📄 Paper + code on the site!
🧵👇
I like the design and interesting choice of company name! Very uncommon for an industrial robot to be this humane.

In January, I started "building something new" with an incredible team. Today I finally get to share some first details about what we've been building. We've called it Walden Robotics (waldenrobotics.com).
I thought long and hard about my own reasons for starting this company. It's not only about the robots. It's also about people. I've tried to capture those thoughts in my first Walden blog post: waldenrobotics.com/news/why-…
It's been an incredible ride so far. Within just a few months of forming the company, we were already operating a general-purpose robot with an end-to-end policy in production in one of the most important factories in North America. It's amazing at how much I've already learned from that experience. There is a lot of work to do, but the mission has never been so clear.
Please help me welcome Walden Robotics into the world. And stay tuned for more updates!
youtube.com/watch?v=fewvZrck…

Rishabh Madan retweeted

1/ Progress in robot locomotion scaled with simulation, but touch was left behind. Our work, Tactile Genesis, unlocks sim for dexterous manipulation. Using sim to ablate tactile types and models, we can quickly converge to better tactile hardware and force-informed policies.
Rishabh Madan retweeted

TACTIC consistently outperforms both model-based and model-free baselines on whole-arm manipulation.
The system is validated on real robots with distributed tactile skin across challenging multi-contact tasks like:
• Turning over a manikin
• Repositioning a person
• Goal reaching through a dynamic 3D maze
A great example of combining learned world models with analytical contact physics instead of relying on either alone.

Rishabh Madan retweeted
Whole-arm manipulation is fundamentally different from grasping.
As contacts form, slide, and break across the entire arm, the robot must reason about both motion and interaction forces—not just end-effector poses.
TACTIC tackles this with a contact-centric controller that jointly reasons over vision, tactile sensing, and robot kinematics to predict future contact states.
Rishabh Madan retweeted

Proud of @madrish02 and the entire team's work on TACTIC. What I find most compelling about TACTIC is that contact is not treated as just another sensor input or a penalty term, it is built into every layer of the planning stack.
In the representation, RGB-D, proprioception, and distributed tactile sensing are fused through a proximity mask that focuses the model on the interaction geometry that actually matters: where contact is happening, and where it may happen next.
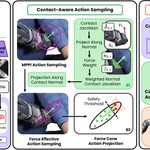
In sampling, contact Jacobians shape MPPI exploration, biasing candidate actions toward directions that can meaningfully regulate forces and steering unsafe samples away from high-force contacts.
In prediction, hybrid rollouts combine learned interaction dynamics with analytical robot kinematics: learn what is hard to model, while preserving the structure we already know. Interestingly, this hybrid variant idea that adds a kinematics-based goal cost during planning also improves planning with other learned world models, including V-JEPA2 on Reach and DINO-WM on Granular.
And in scoring, trajectories are evaluated not only for task progress, but also for contact evolution, force regulation, joint limits, and collisions.
That contact-centricity across representation, sampling, prediction, and scoring is, to me, the most exciting part of TACTIC. Very proud of the team and excited to see this work at #RSS2026! @EmpriseLab @Cornell_Bowers @Cornell_CS

🤖 Robots are usually taught to avoid contact unless it’s at the end effector. But caring for a person, such as rolling them over or repositioning a limb, requires embracing contact along the entire arm. How do we enable robots to perform such contact-rich tasks?
Introducing TACTIC: Tactile and Vision Conditioned Contact-Centric Control for Whole-Arm Manipulation.
#RSS2026 🧵👇
Rishabh Madan retweeted

Whole-arm tactile sensing, a hybrid predictive framework, challenging real-world tasks relevant to pHRI: new work by @madrish02 has many components I find very cool! Check out his work at RSS 2026 this year.
🤖 Robots are usually taught to avoid contact unless it’s at the end effector. But caring for a person, such as rolling them over or repositioning a limb, requires embracing contact along the entire arm. How do we enable robots to perform such contact-rich tasks?
Introducing TACTIC: Tactile and Vision Conditioned Contact-Centric Control for Whole-Arm Manipulation.
#RSS2026 🧵👇
Sadly, I won’t be able to make it to Sydney in person due to visa issues. Huge thanks to my labmate @ZhanxinWu0725 for stepping up to present our work!
Catch the talk at #RSS2026 🇦🇺
🗓️ Manipulation-II — Tue Jul 14, 11:50–12:30
📄 Paper, videos & hardware: emprise.cs.cornell.edu/tacti…