

Macrodata Labs helps robotics teams turn raw physical-world data into better training datasets. https://xitter.cf/t.co/36QOPUfG1a
Joined January 2026
- Tweets44
- Following3
- Followers546
- Likes60



Pinned Tweet
Everyone is betting on Egocentric data to scale robotics 🤖
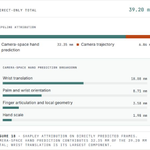
But turning that footage into training data requires recovering the missing action signal: how hands move through 3D space.
We're releasing a new research blog 📜 on how far we can get using only open-source models.
Great work from @DynaRobotics - really cool to see >1M hours of human data being used to study its impact on robot policies.
A crucial part of making this work is turning human trajectories into robot actions. We wrote a blogpost exactly on this topic last week. 👇
macrodata.co/blog/turning-eg…


Today we are introducing Dyna-2, a world-action model pre-trained on one million hours of human video. At this scale, for the first time, we discovered several new scaling laws:
• world-action models exhibit scaling law on human data across four orders of magnitude, from 1000 to 1,000,000 hours,
• this human data scaling law implied a scaling law on never seen robot data,
• both data and objective matter; world modeling and scaling on video data are essential for cross-embodiment scaling transfer to emerge
🧵
On real client footage, open-source systems still struggle with:
- gloves 🧤
- wrist-mounted cameras
- heavy occlusion
- hands belonging to other people
These failure modes are why we're developing our own hand-tracking models for real-world egocentric data.
Have egocentric video?
Send us a small sample and we'll run hand-tracking extraction for free.
The full benchmark, experiments, implementation details, and failure analysis are here 📜
macrodata.co/blog/turning-eg…
Macrodata Labs retweeted

Super cool blog!
The impact of different intervention strategies (small nudge, rewind, letting it fail then correcting) and how policies start trying to correct already successful demonstrations is super interesting
Is there an equivalent to LLM's EOS? Could help maybe?


Does collecting human intervention data (HG-DAgger) actually beat just collecting more demonstrations? I tested this myself:
- interventions reached 72% success
- more demos plateaued at 38% success
I wrote up the experiments:
aurelarnold.xyz/blog/human-i…

Macrodata Labs retweeted

Just boarding my flight to Paris 🇫🇷 for MACHINA Summit.
If your robotics team is spending too much time QA'ing demonstration data or preparing datasets for VLA training, we should talk.

Macrodata Labs retweeted

Bigger is not always better.
In their latest blog post, @macrodata_labs found out that Gemini 3.5 Flash is outperforming all other tested models at robotics subtask annotation. Very interesting!


Macrodata Labs retweeted

We've just published our first blog post!
Teaching robots how to perform long-horizon tasks needs quality annotation of subtasks. Doing it by hand is impractical, so we looked into automating it.
Read about our new benchmark and the 60+ tests we ran. All open-source! 🤖

ALT A diagram of the final, end-to-end, 4-step pipeline we've developed for automated subtask annotation.
Macrodata Labs retweeted
Today we’re releasing our first blogpost!
@physical_int and others are betting on granular subtasks as a key learning signal for long-horizon tasks, but mining them by hand is unscalable🐌
We ran 60+ experiments to find the best VLM-based subtask mining 19x cheaper than humans💰

Macrodata Labs retweeted
Today we're releasing our first blogpost as @macrodata_labs.
We looked into how best to automatically annotate subtasks from robotics 🤖 demonstrations. This can help a lot in long-horizon tasks.
We built a benchmark, ran over 60 experiments, and made everything open-source.
Robots 🤖struggle at new long-horizon tasks. One trick to improve performance is using granular subtask labels ("grab the plate" instead of just "do the dishes").
Today we're releasing our first blog 📜: using VLMs to mine subtasks at scale (19x cheaper than human annotators!)
Finally combining the best segmentation and labeling resulted in 0.201 E2E F1.
Where are the main issues?
- short segments (< 2s) are often missed.
- missing information about end-state of action (fill bottle until it’s full)
- missing information about end-state of action (fill bottle [until it’s full])
- underspecified target/direction

ALT breakdown of segmentation errors by duration and per dataset
The full pipeline is completely open-source. Read the full blog here:
macrodata.co/blog/annotating…
