

Assistant Professor of Robotics, ETH | Core Faculty ETH AI Center | Co-founder Mimic Robotics | MIT PhD '18
Zurich, Switzerland
Joined October 2011
- Tweets88
- Following226
- Followers930
- Likes49


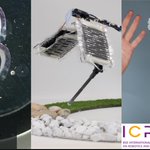


Our #IROS2026 paper presents a musculoskeletal hand powered by remote Peano-HASEL actuators: combining soft forearm muscles with a compliant tendon architecture enables safe, dexterous, and sensorless delicate manipulation, like holding a fragile paper balloon 🎈
Paper: arxiv.org/abs/2603.24357
Talk: 2026.ieee-iros.org/program/c…
Soft robots need shape, material & actuation designed together. Our #IROS2026 paper packs all three into one low-dimensional embedding that works with any black-box simulator: joint co-design beats sequential, with far fewer parameters.
Paper: arxiv.org/abs/2603.06497
Talk: 2026.ieee-iros.org/program/c…
Robert Katzschmann retweeted

The natural final evolution of UMI devices will be the human hand form factor. Why teleoperate when you can just wear the end-effector like a glove.


Robert Katzschmann retweeted

I had a sneak peek last week, during my second visit to MIMIC HQ in Zurich
The handshakes with the U1 glove and the M1 robot hand felt identical. Though M1 has a stronger grip than Stephan (he skips forearm days I'm told)
The blog is a must read to understand the rationale behind the design decisions and requirements


From day one, mimic has been focused on a single goal: general-purpose dexterous manipulation. Today we're proud to announce the mimic hand M1 and the mimic wearable U1.
We believe the only way to solve dexterous manipulation at scale is by going full-stack at the frontier of physical AI, building every layer ourselves around one fixed point, the human hand.
The M1 is a highly backdrivable, tendon-driven hand that covers the full range of human capability, from heavy payloads to fine manipulation.
Robert Katzschmann retweeted

Introducing EgoVerse: an ecosystem for robot learning from egocentric human data.
Built and tested by 4 research labs + 3 industry partners, EgoVerse enables both science and scaling
1300+ hrs, 240 scenes, 2000+ tasks, and growing
Dataset design, findings, and ecosystem 🧵
Robert Katzschmann retweeted

First look at our collaboration with @AudiOfficial on bringing AI-driven robotics into industrial production.
Our end-to-end pixel-to-action model, running on our bi-manual platform, is capable of performing a complex, dexterous and long-horizon insertion task.
Robert Katzschmann retweeted

Thrilled to announce our $7.2M pre-seed round at @AllonicRobotics – a massive kickstart to build the manufacturing foundation for a completely new class of robots! @martonsn @DadaJudith @weiszbart @smleicht @JacklouisP @GoingBallistic5 @lukas_m_ziegler

Robert Katzschmann retweeted

Generative models (diffusion/flow) are taking over robotics 🤖. But do we really need to model the full action distribution to control a robot?
We suspected the success of Generative Control Policies (GCPs) might be "Much Ado About Noising."
We rigorously tested the myths. 🧵👇
Robert Katzschmann retweeted

Newsflash: We raised 16M$ for our seed round 🫡
We're incredibly honored to be partnering with @Elaia_Partners, @speedinvest as well as Founderful (returning!), 1st Kind, 10x Founders, 2100 Ventures and Sequoia Scout Fund.
Robert Katzschmann retweeted

It’s been a wild ride… from four guys in a room at @ETH_AI_Center @mimicrobotics grew to a 20+ people team closing a 16M $ seed round led by @Elaia_Partners and @speedinvest with participation from Founderful, 1st Kind, 10x Founders, 2100 Ventures, and Sequoia Scout Fund!
A lecturer at Kyoto University is building the ORCA hand, he says it’s well designed, we are flattered! orcahand.com


Robert Katzschmann retweeted
Happy to announce mimic-one: a Scalable Model Recipe for General Purpose Robot Dexterity, the culmination of years of research work in dexterous manipulation with imitation learning.
Robert Katzschmann retweeted
mimic builds on top of years of research in end-to-end models for dexterous manipulation. Today, we’re proud to publish mimic-one, outlining the foundations of our autonomous stack. Check out the paper:

Join us May 26, 16:15–17:30 in GLC E 29.2 @ETH for a talk by Prof. Selman Sakar (@EPFL) on harnessing mechanobiology to engineer connective tissues. Learn how robotic microsurgery, microtech & modeling enable biomimetic tissue self-assembly. #ETHZurich #Mechanobiology

Looking forward to give a keynote tomorrow at #ICRA2025 on creating life-like robots based on musculoskeletal designs and living biohybrid technologies.
Join me for the Soft Robotics Keynote Session in the Sidney Marcus Auditorium in Atlanta on Wednesday, 21 May 2025, 8:30am (EDT, UTC-4).
Further details: lnkd.in/difvnyTS

Join us on Friday, May 23, at 4:00 pm CET, for a talk by
Prof. Dr. Cynthia Sung on Salp-Inspired Approach to Underwater Multi-Robot Locomotion as part of our Robotics, Vision, and Controls Talks series!
Zoom: ethz.zoom.us/j/63716670526
More talks: robotics-talks.com

Robert Katzschmann retweeted

Join us on Wednesday, May 21, at 4 pm CEST, for a talk by @HildeKuehne
on Advances in self-supervised multimodal learning as part of our talk series!
Zoom: ethz.zoom.us/j/63716670526Sc……: More talks robotics-talks.com

Robert Katzschmann retweeted
Join us today, Wednesday, at 4 pm CEST, for a talk by @LingjieLiu1 on Towards Next-Gen 3D Reconstruction and Generation: From Visual Fidelity to Multimodal and Physical Understanding as part of our talk series! Zoom: ethz.zoom.us/j/63716670526Sc…:
More talks robotics-talks.com

ALT Lingjie Liu
Robert Katzschmann retweeted

Join us tomorrow, Friday, at 4 pm CET, for a talk by @xiaolonw @UCSanDiego on Modeling Humans for Humanoid Robots as part of our talk series!
Zoom: ethz.zoom.us/j/63716670526
Schedule: robotics-talks.com


Join us on Wed, 12 pm CET, for a talk by @pulkitology @MIT_CSAIL @MIT on Pathway to Robotic Intelligence as a part of our talk series!
The talk will be @ETH_en in person!
Place: HG F 26.5
Zoom: ethz.zoom.us/j/63716670526
Schedule: robotics-talks.com
