
Data infrastructure & foundation models for bimanual robotics. Enabling robots to adapt to new tasks and deploy within days.
San Jose, CA
Joined February 2026
- Tweets28
- Following1
- Followers480
- Likes32


Check out how our model, CFG-1, handles interactive scenarios with people nearby 🤖 Read details at config.inc/blog/260807_habit
We’re releasing HABIT—Human-Aware Behavior and Interaction Training—a high-quality dataset for interactive action models, comprising: 10,563 episodes, 164 hours, 60 tasks.
Trained on HABIT, CFG-1 learns to yield, hand over objects, and pause when needed—supporting safer, more effective collaboration with people 🚀✨
Config retweeted

new submission to datasets .bot: HABIT 🤖🤝👨🏼🦰
in the future, robots will work alongside humans. HABIT is the first dataset with explicit human-robot collaboration.
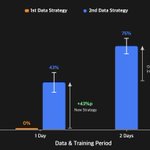
Why it matters: The lesson is about data, not models. Mid-training on HABIT then fine-tuning beats training from scratch at every data budget, so it works as a reusable prior for the whole class of human-present tasks.
thanks for the submission @j__aehwi!

Introducing HABIT — a large-scale robot manipulation dataset for human-present environments, where a person shares the workspace and interacts with the robot in every episode.
60 tasks · 10,563 episodes · 164 hours of rich human-robot interaction.
Toward robots that are not just capable, but safe and socially compatible around people.
habit-dataset.github.io
🧵[1/7]
Config retweeted

Excited to share RoboWorld 🤖
We roll out generalist robot policies from 4,186 real initial scenes, entirely inside a video world model with no robots, and the rankings hit Pearson r = 0.989 (Spearman ρ = 0.970) with the real RoboArena leaderboard. 🧵
[1/7]
Config retweeted

Introducing HABIT — a large-scale robot manipulation dataset for human-present environments, where a person shares the workspace and interacts with the robot in every episode.
60 tasks · 10,563 episodes · 164 hours of rich human-robot interaction.
Toward robots that are not just capable, but safe and socially compatible around people.
habit-dataset.github.io
🧵[1/7]
If you are interested in improving VLM backbones for VLAs, reach out to @Suchaeck and @Jay019374 ! #CVPR2026

🚀 Our paper "Learning Multi-View Spatial Reasoning from Cross-View Relations (XVR)" has been accepted to #CVPR2026!
Current VLMs can reason from a single view surprisingly well, but they still struggle to connect information across multiple viewpoints.
To address this, we introduce XVR:
• 100K-sample VQA dataset
• 3 categories, 8 tasks
• Designed specifically for cross-view spatial reasoning
Most excitingly, cross-view reasoning transfers to robot manipulation.
Using an XVR-trained VLM as a VLA backbone improves RoboCasa manipulation success rates by +13%p on average.
Project page: cross-view-relations.github.…
Paper: arxiv.org/abs/2603.27967
🍿 More details below

Config retweeted

🚀 Our paper "Learning Multi-View Spatial Reasoning from Cross-View Relations (XVR)" has been accepted to #CVPR2026!
Current VLMs can reason from a single view surprisingly well, but they still struggle to connect information across multiple viewpoints.
To address this, we introduce XVR:
• 100K-sample VQA dataset
• 3 categories, 8 tasks
• Designed specifically for cross-view spatial reasoning
Most excitingly, cross-view reasoning transfers to robot manipulation.
Using an XVR-trained VLM as a VLA backbone improves RoboCasa manipulation success rates by +13%p on average.
Project page: cross-view-relations.github.…
Paper: arxiv.org/abs/2603.27967
🍿 More details below
Given the recent wave from @RhodaAI and @GeneralistAI—had to join the memory challenge 😄
Memory shouldn’t stop at shell games—check out our robot playing “Runaway” by @kanyewest 🎹
and more in our latest blog: config.inc/blog/memory_previ…

GEN-1 plays the 🐚 shell game, trained on just 1 hr of robot data. It also generalizes to unseen objects, like @BerkayAntmen 's car keys.
Physical AI models should be capable of benchmark tasks like this one. It's interesting for the all the reasons @RhodaAI calls out -- requires visual memory, and the model must track the cups from the very start, at high frame rates.
Interestingly, GEN-1 appears to exhibit a degree of "active perception." It's subtle; the hands can sometimes appear to "follow" the cups, using its own movements to help attend to where it thinks the object should be.
Read more about GEN-1 in our blog post in the comments below ↓
Config retweeted

Meet the next wave of robotics startups. 🤖
The AWS x @MassRobotics Fellowship cohort is advancing real-world robotics across agriculture, manufacturing, humanoids and beyond.
From autonomous farming to AI-driven automation, #NVIDIAInception members @burro_ai, @config_inc, Deltia, @HaplyRobotics, Luminous Robotics, @roboto_ai, Telexistence, Terra Robotics, and WiRobotics are shaping the future of physical AI. 📖 nvda.ws/3O2SBSL
#NationalRoboticsWeek


Most robot data is collected in human-free environments — but the real world is not.
We're closing that gap by collecting human-present data.
Our models learn to naturally pause, yield, and collaborate!
Blog post: config.inc/blog/hrc_preview
🧵1/N
Left is a model trained on human-absent data collides with a person. Right is our model, trained on human-present demonstrations, works safely alongside them.
Models trained the conventional way — on human-absent data — simply don't develop these behaviors. They collide with a person in the way, and they don't wait when someone is nearby.
🧵2/N
We see this as an important step toward robot foundation models that are ready for the places where people actually live and work — homes, factories, care facilities.
If you're interested in our data, models, or just want to talk, we'd love to hear from you at forms.config.inc/contact
This is led by @Jay019374 with @hyungmokson @kimin_le2
🧵N/N

Excited to share that we've been selected for the second cohort of the MassRobotics Physical AI Fellowship!
We're proud to join an incredible group of companies pushing the boundaries of Physical AI.
If you're heading to GTC, let's connect!
#PhysicalAI #Robotics #MassRobotics #Fellowship #GTC2026

MassRobotics is excited to announce the second cohort of the Physical AI Fellowship powered by @awscloud Startup and @nvidia Inception.
🤖 2026 Cohort: @burro_ | @config_inc | Deltia | @HaplyRobotics | Luminous | @roboto_ai | Telexistence | Terra Robotics | WIRobotics Inc.
Learn more here: massrobotics.org/physical-ai…
@AWSstartups | @NVIDIARobotics

Hello world 🤖👋🏻—We are Config.
Today, we’re excited to share a preview (🔗 config.inc/blog/tech_preview) of what we’ve been building. Our mission is to make robots capable of reliably performing two-handed tasks across diverse real-world settings materially more cost- and time-efficient to deploy.
6/ See the resulting policy after two rounds of online-data driven improvement on the popcorn-serving task
7/ Check out how models trained through our pipeline perform across additional tasks on our YouTube channel: 🔗youtube.com/@config_inc_admi… 🤖🦾🤖🦾