


Ajay Chintala retweeted
Robots that generalize to the real world need lots of diverse training data to build robust models. But collecting that data is a huge challenge.
That’s why we built TeleOp-XR: an open system to teleoperate robots in Augmented Reality! 🤖✨
A quick demo and instructions 🧵⬇️
Ajay Chintala retweeted

What did I say earlier?
Glasses (Holodecks) and robots go together like peanut butter and jelly.

Robots that generalize to the real world need lots of diverse training data to build robust models. But collecting that data is a huge challenge.
That’s why we built TeleOp-XR: an open system to teleoperate robots in Augmented Reality! 🤖✨
A quick demo and instructions 🧵⬇️
TeleOp-XR is modular:
- Support new robots by editing a config file
- Define custom AR menus for your tasks and bind them to actions in the backend
- Plugin-like architecture to easily support new robot backends
1
3
212
Ready to collect better data for your robots?
- Clone the repo from github.com/ajhai/teleop-xr
- Add your robot config
- Start teleoperating and recording in AR
Towards generalizable robots—one episode at a time! 🚀

7
197
Just started writing an MCP server for FreeCAD and thought I will do a quick search before going too far
Aaand yes, looks like someone just wrote one
xitter.cf/neka_nat/status/190125…

1
7
589
NVIDIA GROOT N1 model is already available on HF 🤗
Looks like the 🔗 is broken in the announcement page. Correct url in the reply

NVIDIA announced GR00T N1, the first fully customizable open-source humanoid robot foundation model, designed to advance general-purpose robotics.
⦿ A dual-system AI inspired by human cognition: System-1 handles fast, intuitive actions, while System-2 enables methodical decision-making. System-1 is trained on human demonstration data and a massive amount of synthetic data.
⦿ GR00T N1 can easily generalize across common tasks - such as grasping, moving objects with one or both arms, and transferring items from one arm to another - or perform multistep tasks that require long context and combinations of general skills.
⦿ CEO of 1X: "With a minimal amount of post-training data, we were able to fully deploy on NEO Gamma - furthering our mission of creating robots that are not tools, but companions that can assist humans in meaningful, immeasurable ways."
⦿ Early adopters also include Agility Robotics, Boston Dynamics, Mentee Robotics, and NEURA Robotics.
1
3
426

This couldn't come at a better time. We are betting on the fact that the robotic foundation models are going to get better, really fast 🚀
So our plan is to build affordable and capable hardware, ship the models as and when they are available, making the robot smarter with every update

Meet Gemini Robotics: our latest AI models designed for a new generation of helpful robots. 🤖
Based on Gemini 2.0, they bring capabilities such as better reasoning, interactivity, dexterity and generalization into the physical world. 🧵 goo.gle/gemini2-robotics
3
6
535
Ajay Chintala retweeted

Really cool little two armed home robot, powered by llms vlms and end to end policy learning. The wheeled form factor is a good for for homes for price and safety reasons. Looking forward to seeing more about this.
Hello world, meet Anna – our first prototype of an affordable, general-purpose household robot 🤖
It uses a combination of LLMs, VLMs, and VLAs to understand language, perceive surroundings, and automate 🏠 chores seamlessly.
We chose the wheeled form factor over bipedal for its simple yet functional design. For the first generation embodied AI in homes, we believe this form factor wil be friendly and less intimidating than the alternatives.
A simpler design also helps with our goal of making these robots affordable. We are hoping to ship these devices for under $5k
In the coming weeks, we will share an updated prototype that will be closer to our production design and includes vertical movement that is critical for most household chores.
⬇️ is a quick demo of Anna, responding to voice and handing tasks end to end
Ajay Chintala retweeted
Hello world, meet Anna – our first prototype of an affordable, general-purpose household robot 🤖
It uses a combination of LLMs, VLMs, and VLAs to understand language, perceive surroundings, and automate 🏠 chores seamlessly.
We chose the wheeled form factor over bipedal for its simple yet functional design. For the first generation embodied AI in homes, we believe this form factor wil be friendly and less intimidating than the alternatives.
A simpler design also helps with our goal of making these robots affordable. We are hoping to ship these devices for under $5k
In the coming weeks, we will share an updated prototype that will be closer to our production design and includes vertical movement that is critical for most household chores.
⬇️ is a quick demo of Anna, responding to voice and handing tasks end to end
Ajay Chintala retweeted
Why do robots need to be humanoids? They don't.
The race to get one into our homes is on.
18 months turns this into a smooth, confident, charismatic robot that is affordable, manufacturable at scale, and much more capable.
If I'm wrong, 36 months.
Which isn't long at all.
Lots of my friends in Silicon Valley say AGI is coming before then too.
Into a new world we are about to go.
Hello world, meet Anna – our first prototype of an affordable, general-purpose household robot 🤖
It uses a combination of LLMs, VLMs, and VLAs to understand language, perceive surroundings, and automate 🏠 chores seamlessly.
We chose the wheeled form factor over bipedal for its simple yet functional design. For the first generation embodied AI in homes, we believe this form factor wil be friendly and less intimidating than the alternatives.
A simpler design also helps with our goal of making these robots affordable. We are hoping to ship these devices for under $5k
In the coming weeks, we will share an updated prototype that will be closer to our production design and includes vertical movement that is critical for most household chores.
⬇️ is a quick demo of Anna, responding to voice and handing tasks end to end
Hello world, meet Anna – our first prototype of an affordable, general-purpose household robot 🤖
It uses a combination of LLMs, VLMs, and VLAs to understand language, perceive surroundings, and automate 🏠 chores seamlessly.
We chose the wheeled form factor over bipedal for its simple yet functional design. For the first generation embodied AI in homes, we believe this form factor wil be friendly and less intimidating than the alternatives.
A simpler design also helps with our goal of making these robots affordable. We are hoping to ship these devices for under $5k
In the coming weeks, we will share an updated prototype that will be closer to our production design and includes vertical movement that is critical for most household chores.
⬇️ is a quick demo of Anna, responding to voice and handing tasks end to end
Chassis for this prototype was designed in @FreeCADNews and the arms are @therobotstudio's Standard Open Arm 100 designs.
⬇️ is our teleop setup that we are using to collect training data for manipulation models

Follow @VexaRobotics for updates and if you want to be notified when the pre-orders open up.
4
965
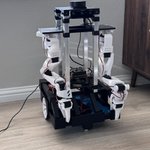
And this is our fully assembled robot prototype 🤖
Designed the chassis in FreeCAD and using SO-ARM100 arms by RobotShop
Still figuring out the right approach for vertical movement mechanism.. 🔼 Once integrated, they should expand the reach and unlock a lot more tasks the robot can perform...

