

multi-agent & multi-robot research @AIResearchAIST ← @Cambridge_CL ← PhD @tokyotech_en / tweets are my own
Tokyo 🗼
Joined June 2013
- Tweets5.5K
- Following258
- Followers2.4K
- Likes5.6K


Pinned Tweet
Super excited to share that our work is now published in Nature Portfolio #npjRobotics 🥳
"Concrete Multi-Agent Path Planning Enabling Kinodynamically Aggressive Maneuvers"
K Okumura, G Yang, Z Gao, H Woo & A Prorok
📄Paper nature.com/articles/s44182-0…
📽️Video youtube.com/watch?v=41kPW6Jw…
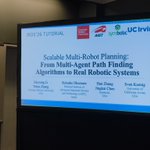
Tutorial on Scalable Multi-Robot Planning: From MAPF Algorithms to Real Robotic Systems
youtube.com/watch?v=EkfmFfDh…
#IROS2026 で行った、マルチエージェント経路計画の実ロボ展開へ向けてのチュートリアル録画が公開されました

拡散モデルのデノイジング機構を利用したマルチロボット軌道生成の論文が、ロボティクス系のトップジャーナルであるIEEE T-ROに掲載されました、めでたいっ 🎉
Excited to share that our work on multi-robot trajectory planning has now been published in IEEE Transactions on Robotics @IeeeTro 🥳
"Denoising Multi-Robot Trajectories"
Y Zhang, KO, A Shankar & A Prorok
🔗 Paper ieeexplore.ieee.org/document…
📄 arXiv arxiv.org/abs/2609.35651
We demonstrate the versatility of the framework through large-scale planning with 100 simulated robots, zero-shot deployment on 10 real drones, and fully onboard distributed lifelong operation with six ground robots.
🎬 Video youtube.com/watch?v=sK6mr42a…
Through this project with my colleagues at Cambridge, I have enjoyed sampling-based optimisation – a different planning paradigm to combinatorial search. Many thanks to my co-authors 😊
💻 Code github.com/proroklab/d4orm
Excited to share that our work on multi-robot trajectory planning has now been published in IEEE Transactions on Robotics @IeeeTro 🥳
"Denoising Multi-Robot Trajectories"
Y Zhang, KO, A Shankar & A Prorok
🔗 Paper ieeexplore.ieee.org/document…
📄 arXiv arxiv.org/abs/2609.35651
Building upon our D4orm (IROS'25), this journal extension takes diffusion-inspired multi-robot trajectory optimisation further, with additional theoretical analysis and new planning architectures for decoupled, online, and distributed operation.
IROS'25: arxiv.org/abs/2503.12204

Keisuke Okumura retweeted

ラズパイマウスの群れが攻めて来たぞ!🐀🤖
Excited to share our latest work on multi-robot learning, to be presented at #CoRL2026 !
"Learning Coordinated Visuomotor Box-Pushing from Solo Demonstrations"
R Matsumoto, M Kinjo, Y Sasaki & KO.
📄 Paper arxiv.org/abs/2610.05677
🎥 Video youtube.com/watch?v=J9KfPI-h…
ロボット学習の国際会議CoRL-26の採択論文を公開しました🎉
協調タスクを解く自律分散ポリシーを、ロボット1台のテレオペデータだけから、模倣学習で設計できるか?というお話
Excited to share our latest work on multi-robot learning, to be presented at #CoRL2026 !
"Learning Coordinated Visuomotor Box-Pushing from Solo Demonstrations"
R Matsumoto, M Kinjo, Y Sasaki & KO.
📄 Paper arxiv.org/abs/2610.05677
🎥 Video youtube.com/watch?v=J9KfPI-h…
Excited to share our latest work on multi-robot learning, to be presented at #CoRL2026 !
"Learning Coordinated Visuomotor Box-Pushing from Solo Demonstrations"
R Matsumoto, M Kinjo, Y Sasaki & KO.
📄 Paper arxiv.org/abs/2610.05677
🎥 Video youtube.com/watch?v=J9KfPI-h…
So, can robots learn to coordinate from solo demonstrations? We systematically investigates this question using up to 40 robots, each operating with an onboard decentralised visuomotor policy without comm.
See you in Austin 🇺🇸 next month
corl.org/

終わり、3年前からはこうなっていると思わなかったよ
kei18.github.io/note/posts/2…


