
Research Intern @AdobeResearch, CS Ph.D. student @UWMadison | prev. intern: @AdobeResearch; @Krafton_AI
Madison, WI
Joined October 2023
- Tweets65
- Following679
- Followers135
- Likes403




Pinned Tweet
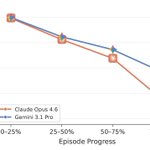
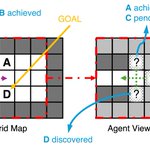
We all knew LLM agents struggle to explore, but we had to eyeball it 👀. We couldn't measure exploration errors. Until now. 🗺️🤖
We built a policy-agnostic metric to quantify exploration and exploitation errors in LLM agents.
Spoiler: Exploration error is what kills📉 agent performance in our setting 👇🧵(1/8)

Our lab has a robot now! And a robotics paper. Amazing work @trungdt880 🦾🦾

thaw-vla.trung-dt.com
My first robotics paper is out 🤖
World models are basically robotics' smartest friend who thinks 7 times before answering any question. great with text, terrible at parties 🥺
So we asked: can we keep the brain and lose the lag? THAW-VLA 🧵
(1/n)
I am attending #SIGGRAPH2026 to present “MAOAM: Unified Object & Material Selection with Vision-Language Models” next week (July 23rd Thursday, 11:35-11:45 am at room 408)!
MAOAM is a unified segmentation model that can select both objects and materials under click- and text-based interactions. 🧵(1/9)

Also, feel free to try our model out and check out the data released! 🧵(8/9)
- HF demo: huggingface.co/spaces/jpark6…
- HF dataset: huggingface.co/datasets/jpar…

Huge thanks to my co-authors @vdeschaintre, Jason Kuen, Kangning Liu, @iliyang, @Krishnakusin, @yong_jae_lee, @michi_fischer! 🧵(9/9)
+ If you are attending SIGGRAPH, I’d love to connect, especially if you are working on physical AI, robotics or world (action) models! Feel free to reach out :)
Jaden Park retweeted

The reversal curse. Edits that don't suppress negations. Multi-hop updates that don't propagate. These look like separate bugs.
Our ICML 2026 spotlight argues they may share a common geometric origin, visible only when you study how representations move under updates 🧵
(1/11)

Jaden Park retweeted

Almost all "flagship" models are now MoEs.
But smaller models still prefer to be dense as they target memory-constrained scenarios where total params matter.
So we ask: Can we leverage an MoE to produce dense models without having to train them from scratch?
🧵👇

Lots of good news this week! 🚀
1. My internship project from @AdobeResearch has been accepted to #SIGGRAPH2026!
("MAOAM: Unified Object & Material Selection with Vision-Language Models")
Special thanks to my wonderful mentor @michi_fischer who has made this project possible!
2. Paper accepted to #ICML2026!
("DocHop: Benchmarking Out-of-domain Multi-hop Reasoning in Information-Dense Documents")
3. Paper accepted (with minor revisions) at #DMLR!
("Decomposing Complex Visual Comprehension into Atomic Visual Skills for Vision Language Models")
In both papers, we generate carefully designed benchmarks to tackle compositional/multi-hop reasoning in VLMs. Proud to have contributed in these projects.
More detailed posts soon :) Stay tuned!
Jaden Park retweeted
We all knew LLM agents struggle to explore, but we had to eyeball it 👀. We couldn't measure exploration errors. Until now. 🗺️🤖
We built a policy-agnostic metric to quantify exploration and exploitation errors in LLM agents.
Spoiler: Exploration error is what kills📉 agent performance in our setting 👇🧵(1/8)
I will be at #ICLR2026 to present my work on data contamination in VLMs! (Fri, Apr 24, 2026 • 8:30 AM – 11:00 AM, Pavilion 3 P3-917)
I am currently interested in VLA/physical AI, agents and robustness/generalization.
Would love to chat and connect with anyone with similar interests :)

Me: memorize past exams 📚💯
Also me: fail on a slight tweak 🤦♂️🤦♂️
Turns out, we can use the same method to 𝗱𝗲𝘁𝗲𝗰𝘁 𝗰𝗼𝗻𝘁𝗮𝗺𝗶𝗻𝗮𝘁𝗲𝗱 𝗩𝗟𝗠𝘀! 🧵(1/10)
- Project Page: mm-semantic-perturbation.git…

Can we improve exploration failures in LM agents? 🛠️
🗺️ Exploration Prompts: Explicitly injecting exploration strategies increases success rate by 17%.
📝 Explicit Harness: Providing the agent with structured summaries of its past observations; success rate boost by 29.4%! 🧵(7/8)
This was a joint co-first author work with @jungtaek_kim and @jongwonjeong123, with the guidance from @rdnowak, @Kangwook_Lee and @yong_jae_lee.
If this sounds interesting, please check out our paper 📄 arxiv.org/abs/2604.13151!
If you have any questions, feedback, or new ideas, I'd be more than happy to discuss!🧵(8/8)
