
CS PhD (Robotics) @ Cornell | Prev UC Berkeley
Joined March 2023
- Tweets60
- Following531
- Followers147
- Likes917



Pinned Tweet
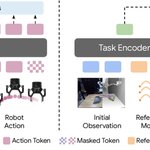
Introducing Unified Motion-Action (UMA) Model, a robot foundation model that uses 3D object motion as a shared interface for heterogeneous robot learning. UMA treats motion and action as co-evolving variables, enabling knowledge transfer across data sources and versatile inference. 🧵 1/n
Yunhao Cao retweeted

Humanoids can learn new skills by tracking high-quality reference motions, which today come from humans through motion capture or video. Routing every reference through a human proxy limits scalability and compounds reconstruction errors with the embodiment gap. KinoGen synthesizes loco-manipulation references directly for the target robot through kinematically grounded video generation. 🧵 (1/7)
I'm presenting COIL at two #IROS2026 workshops today! 🤖
🕥 10:30–11 AM · CompRobotics workshop poster (Rm 408/409)
🕒 3:15–4:15 PM · WORLDS workshop poster (Rm 301/302)
Come by and ask questions, discuss open problems with me!


Mimo just announced their new VLM model series. This will be huge for the robotics field since they showcase its capability to perform manipulation tasks like astra. The difference here is that MiMO is already open-sourced and available for VLA finetuning.

Introducing Xiaomi MiMo-V2.6 — Pro & Flash.
Frontier intelligence, all the modalities, built in public.
🔹 Two omnimodal models, advancing through scaled reinforcement learning
🔹 Pro performs on par with Claude Opus 5 and GPT-5.6 Sol across most agent benchmarks
🔹 Pro scores 46 on the Artificial Analysis Intelligence Index — the highest among open-source models
🔹 Stronger coding, computer use, 3D reasoning and creative capabilities
🔹 Open model weights, technical report, RL environments and training code
Blog:mimo.xiaomi.com/mimo-v2-6

Yunhao Cao retweeted

How can generalist policies learn new skills without losing their pretrained prior?
We introduce Proxy Policy Steering (PPS), which uses proxy policies to steer the frozen base policy at inference, adding task-specific behavior without touching its weights.
I definitely agree. I think Astra is the first pretrain using synthetic text data generated from robot data, so further finetuning with an action head is easier since a subspace of the text embedding would already be robot actions. We'll probably see an openai vla soon.

gpt-6 for robotics is truly a step change, but there's a reason for it and a bigger implication
very likely (duh) it was trained on robotics data, predicting end effector movement at least (e.g. "the position of the hand")
of course, it's slow, but if you're working on a task that does not require speed nor reflexes, then it is surprisingly powerful!
now if they have this data, they don't have to stop there. very likely we will see soon one of their first actual robotics models!
and hopefully quickly available in the api :)
Yunhao Cao retweeted

Behavioral cloning mystery
seohong.me/blog/behavioral-c…
I wrote a new blog post about "mysteries" in behavioral cloning that appear with real-world robot data (e.g., overfitting is "good"). I also tried to demystify them and shared my thoughts!

Yunhao Cao retweeted

Introducing KITE 🪁, a paradigm that transfers the interaction intent instead of joint-space actions across structurally different manipulators. Deploying on a new robot needs only its kinematics model (URDF), no new task demonstrations. 🧵1/8

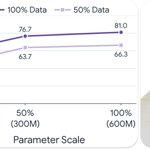
Our analysis isolates the design choices that matter, confirms that UMA scales with both data and model size, and traces its remaining errors to execution rather than perception. 10/n

Check out our paper and project page for more details!
🌐 Website: uma-manipulation.github.io/
📝 Paper: arxiv.org/pdf/2606.16917
Huge thanks to my collaborators Shitong Liu, @chaof1234 , Meryl Zhang, @XuanchenLu , and mentors @andrewhowens , @KuanFang .
CorDex utilizes 3D contact keypoints to transfer grasping knowledge from single human demonstrations to hundreds of synthetic objects. Check out our work on ArXiv!

🚀Excited to share our #ICRA2026 work, CorDex!
CorDex learns functional dexterous grasping from a single human demo, generalizes to unseen objects using a single-view observation, and enables robots to use tools for long-horizon tasks.
Project Page: cordex-manipulation.github.i…
Yunhao Cao retweeted

Introducing Any4D, a unified transformer for fully feed-forward, dense, metric-scale 4D reconstruction from flexible inputs!
Any4D regresses per-pixel motion + geometry across frames in one pass — 15× faster, 2–3× more accurate reconstructions ⚡📈
Details + code below 👇
Exciting collab with @Nik__V__ @YuchenZhan54250 Tanisha Gupta @akashshrm02 @smash0190 @RamananDeva