

contributing to @SeismicSys @inconetwork @PrismaXai
Thailand
Joined January 2022
- Tweets8.4K
- Following2.7K
- Followers355
- Likes4.6K




@PrismaXai put it bluntly: no robot is safe. Not the one dancing. Not the one folding laundry. You cannot sandbox a 50 kg machine or roll a bad move back. An LLM that gets it wrong gets regenerated. An arm that gets it wrong goes through the table.


@PrismaXai opened Robotics Data in limited release. 120,000+ episodes already delivered, across 1,700+ scenarios. Teleoperation and egocentric clips, reviewed to one standard, growing every month. Not a demo reel. A data bank.

1
3
14
@PrismaXai opened Robotics Data in limited release. 120,000+ episodes already delivered, across 1,700+ scenarios. Teleoperation and egocentric clips, reviewed to one standard, growing every month. Not a demo reel. A data bank.
At IROS, @PrismaXai asked one question: what makes good robotics data? Not hours. Not pretty clips. Data built for the model you are training. A VLA, a world model, and a kinematics model do not want the same set.

At IROS, @PrismaXai asked one question: what makes good robotics data? Not hours. Not pretty clips. Data built for the model you are training. A VLA, a world model, and a kinematics model do not want the same set.
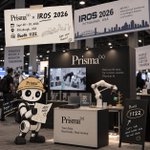
@PrismaXai is live at IROS 2026 now. Booth 1122 in Pittsburgh, through Oct 1. Tomorrow the CEO talks at 3:15 PM on one question: what makes good robotics data. That is the whole thesis on a stage.

1,096,361
1BTC = 1MBTC
.-- . / .-- .. .-.. .-.. / ... . -.-. ..- .-. . / .---- --..-- ----- ----. -.... --..-- ...-- -.... .---- / ... .- - --- ... .... .. / -... - -.-. .-.-. memebitcoin.org/register

1
10


@PrismaXai is live at IROS 2026 now. Booth 1122 in Pittsburgh, through Oct 1. Tomorrow the CEO talks at 3:15 PM on one question: what makes good robotics data. That is the whole thesis on a stage.
IROS 2026 starts in 3 days. Pittsburgh, Sept 28–30.@PrismaXai will be at Booth 1122. This is not a crypto meetup. It is one of the main rooms where robotics labs and builders compare what actually works.

IROS 2026 starts in 3 days. Pittsburgh, Sept 28–30.@PrismaXai will be at Booth 1122. This is not a crypto meetup. It is one of the main rooms where robotics labs and builders compare what actually works.
VLA means Vision-Language-Action. The model sees the scene, reads the task, then outputs the next move. Not a chatbot. Not a robot body. It is the brain that turns a view into work.
@PrismaXai

VLA means Vision-Language-Action. The model sees the scene, reads the task, then outputs the next move. Not a chatbot. Not a robot body. It is the brain that turns a view into work.
@PrismaXai
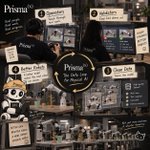
The PrismaX loop is simple. Operators teach through real work. Validators keep bad demos out. Clean data trains the model. A better model makes the next robot run cleaner. That cycle is the product. @PrismaXai

The PrismaX loop is simple. Operators teach through real work. Validators keep bad demos out. Clean data trains the model. A better model makes the next robot run cleaner. That cycle is the product. @PrismaXai
A side camera can make a demo look perfect. The robot still acts from its own eyes. If the dataset never sees the world from the wrist or head, the model is learning the wrong view. That gap is called missing egocentric data. @PrismaXai

A side camera can make a demo look perfect. The robot still acts from its own eyes. If the dataset never sees the world from the wrist or head, the model is learning the wrong view. That gap is called missing egocentric data. @PrismaXai
People think teleoperation is a temporary crutch. It is not. Robots can move. They still do not know which moves are worth copying. A human in the loop is how real skill enters the dataset. @PrismaXai

People think teleoperation is a temporary crutch. It is not. Robots can move. They still do not know which moves are worth copying. A human in the loop is how real skill enters the dataset. @PrismaXai
@PrismaXai is heading to IROS 2026 in Pittsburgh, Sept 28–30, Booth 1122. IROS is where robotics labs and builders meet. Showing up there means the data layer wants a seat next to the hardware.

@PrismaXai is heading to IROS 2026 in Pittsburgh, Sept 28–30, Booth 1122. IROS is where robotics labs and builders meet. Showing up there means the data layer wants a seat next to the hardware.
More robots do not automatically mean better Physical AI. A hundred arms making messy demos still teach the wrong habits. One clean dataset beats a warehouse of noisy clips. The bottleneck is quality, not headcount. @PrismaXai

More robots do not automatically mean better Physical AI. A hundred arms making messy demos still teach the wrong habits. One clean dataset beats a warehouse of noisy clips. The bottleneck is quality, not headcount. @PrismaXai
A robot clip can look clean and still be bad training data. If the hands leave the frame, the cameras drift, or the task never finishes, the model learns the wrong lesson. Smooth is not the same as useful.
@PrismaXai
