





Javier Isabel retweeted

Efemérides. Hace poco más de 15 años (finales de Septirembre de 2011) de la charla "Robots Libres e imprimibles" dada en la mítica OSHWCon 2011 de Madrid
El proyecto CloneWars estaba en sus inicios...
obijuan.github.io/iearobotic…


Javier Isabel retweeted

🤖 EchoEar × Kame32 Concept • STL files
➡️ Download 3D print model: cults3d.com/:3673074
💡 Designed by @javierih
#3DPrinting #3DPrinter #Printable #STLfile


Nice work on your robot! I really appreciate what you’ve built. Since it’s based on my MiniKame design (released as open source under CC BY-SA), please keep the same license. Your derivative should also be CC BY-SA, not CC BY-NC-SA. Thanks!!! @digikey

Just here to announce my Comet Crawler v1. Is now open source. #maker #robot
digikey.com/en/maker/project…


Javier Isabel retweeted
Los Pcbs del proyecto robot #kame32 de @JavierIH fabricados por @PCBWayOfficial ya están en casa.
👇🏻
javierih.com/robots/kame32/
👇🏻
pcbway.com/project/shareproj…
Tan eficientes como siempre 👏🏻👏🏻👏🏻

By the way, did you know you can MAKE your own flutes online using an open‑source JavaScript library? 🤯 Check it out: unityrobot.github.io/Flutoma…


Tuning Kame32's gait in real time by tweaking oscillators parameters on the fly. I'm using the web joystick input to modulate them proportionally.
Javier Isabel retweeted
Mis primeros pasos estudiando un poco el código que has hecho, tiene muy buena pinta la verdad 👏🏻👏🏻👏🏻👌🏻 😉


Javier Isabel retweeted
Recordando el pasado: Cube Revolutions:
Este robot modular de tipo gusano puede auto-reconfigurarse para moverse de diferentes maneras. En este experimento se convierte en una rueda, lo que le permite moverse a mucha mayor velocidad!
youtube.com/watch?v=f3rr1lcF…

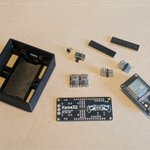
Just published a quick guide on how to assemble the Kame32 PCB. If you ever plan to build this robot, this might come in handy!
Check it out on my website: javierih.com/aux/kame32-pcb/

Javier Isabel retweeted
Este vídeo (de hace 17 años) es el que utilicé en mi tesis para explicar al tribunal los diferentes modo de caminar del robót ápodo hypercube, de 8 grados de libertad
Todos los movimientos están hechos con osciladores, por eso son tan suaves y naturales
youtube.com/watch?v=RJL-buxN…
