

Building and Founding Vertex Robotics I train my robots on 100% synthetic data Robotics | Calisthenics | Piano | Tech | Investing Follow for more!
Joined September 2019
- Tweets526
- Following206
- Followers516
- Likes1.1K


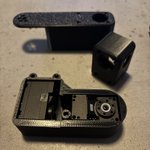


First 5 DoF leg assembled (hip pitch not in image)
I (clanker) made some small tweaks in design for better printing and cable management
100% designed by clanker™️

Tip for anyone in business:
PLEASE somewhere in your automated mails add the general term of what you do!
I sold an apartment last year but idk the name of the notary and searching for "notary + {address}" gives no results which SUCKS
Again 2026 is crazy.
This morning my clanker designed 10 DoF lower side of humanoid, now have parts semi assembled with perfect fits


Ok should I build this instead?
5 DoF legs with pitch then abduction instead of other way round, this gives way more abduction range.
Complete redesign done by Clanker™️

So... I'm already considernig throwing away this new design. Abduction first makes its range very limited
Should I swap it so I do hip pitch first, then abduction and then add another pair of motors for hip yaw?!
That would make the most versatile setup and I'm waiting for PCB anyway...
Hear me out;
LLMs are almost at the point where they don't need to become smarter for 99% of people (e.g. robotic dev)
Then it will be all about speed and I'm building a fully automated feedback loop app for robotics development
When LLMs start doing 1000+ tok/s, tool calls will become an INSANE bottleneck in comparison
So everything around the LLM needs to be FAST. No excuses
30 min on L4 training to get stable policy
Currently printing parts and tweaking design + waiting on PCB. Building FAST
Started this variation yesterday, let's see total time to physical walker


Morning all! What is everyone working on this week?
I am probably going to add abduction joints to Vertex Mini (+ that's a hint to what's next)
And start new design of my big robot so it can get a Jetson and @RealSenseai

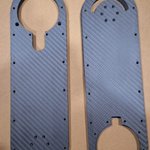
Just got this image from China where they are cutting my custom carbon plates.
8 plates, 85mm wide and 295mm tall. 60$ including shipping.
Can't wait for them to arrive but will take a bit


Who knows where I can download 电机调试助手 from @UnitreeRobotics?
I have the digital servo's but it appears the motor debugging tool can nowhere be downloaded?
But it is required to change the IDs of the servos as explained in their docs...

Anyone want to try my new robotics platform with focus on RL?
Fully agentic, I provide initial credits for free in exchange for feedback.
Personally using it to do 100% of the development of mini version of my bot