

The world's open robotics lab. Apply now.
bitrobot.ai
Joined November 2024
- Tweets1.6K
- Following1.8K
- Followers11K
- Likes4.6K





BitRobot 🦾 retweeted

Special Shoutout to our friends in @anvil_robotics @AGIBOTofficial @MeckaAI @xdofai @robocurve @cortexairobot @makermodsai @GenrobotAI @eastworlds_io @BitRobotNetwork @ScaleAILabs @LeRobotHF @huggingface @roborobots @ROBOTIS for helping us with our early beta testing across Asia, Europe, and the Americas Europe and America 🌍.
A truly global stress test of Dream-1 before our launch!

Congrats to @axisrobotics on their TGE.
SN/04 contributors who completed the Axis Alliance tasks were rewarded twice, in Axis points and BitRobot Bolts.
We're building the world's open robotics lab. Start here and earn: app.bitrobot.ai

Thanks @KhalaResearch for this deep dive into robot learning and how industry leaders are tackling the data bottleneck.
Great to see our subnet partner @axisrobotics featured alongside BitRobot’s ecosystem crowdsourcing data across teleoperation, simulation, and ego video!


Robotics is still waiting for its "ChatGPT" moment
Language models had the internet to learn from, while robots need diverse physical demonstrations that are expensive to collect
Bessemer estimated just 300,000 hours of robot manipulation data globally in April, while others believe robotics could require 100M+ training hours
Bessemer projects $3B+ in robot-data spending over two years
Open networks are using crypto incentives to coordinate contributors across simulation, teleoperation and human video collection
Axis reports 7M+ trajectories from 220K+ contributors, with its data lifting task success from 83.9% to 88.8% on the LIBERO-Plus simulation benchmark
Our latest report explores the data opportunity through Axis, BitRobot, Eastworlds & THOR
Full report in the next post below

Join us and other teams from Dyna, 1X, Physical Intelligence, and more. luma.com/humanoid-hub-confer…

We're joining @TheHumanoidHub for their inaugural conference in SF today and tomorrow alongside @GroundedSI
Meet the team, get hands-on with our RoboCap + RoboWrist bundle, and see SOTA data enrichment in action.
Register below ↓


Thank you @atlasberry008 for this in-depth intro to the RoboCap platform with data enrichment from @GroundedSI
We're cooking new earning opportunities for the RoboCap subnet in the coming weeks. Stay tuned 👀

BitRobot will pay you to wear a $500 hat at work.
Six cameras, pointed at your hands.
Robots have almost no training data, but people have all of it.
So the hats are going into bakeries, hotels and factories.
I would rather own what the humanoids learn from than fund the humanoids.
Congrats to the 9 teams and thanks to the co-organizers @lightwheelAI @singaporetech @unitreerobotics for making the first humanoid IKEA assembly challenge happen.
Excited to see where the benchmark goes. Follow here for info about the next competition: humanoid-ikea-assembly-chall…

A major robotics challenge is getting lab-trained policies to work reliably in the real world. Lighting, noise, crowds, and unfamiliar settings are all externalities.
That’s why we run the Grand Challenges: to test generalization in new environments, measure consistency, and set benchmarks that push robotics beyond the lab.
To help teams prepare, @LightwheelAI developed a high-fidelity simulation of the Unitree G1 and IKEA UTTER table, recreating the competition environment and assembly tasks.
We also released teleoperation episodes and egocentric video data to help teams train their policies. @singaporetech supported with remote evals.
All datasets are available on Hugging Face: huggingface.co/BitRobot

Assembling a table involves many steps to plan and sequence: the robot must walk to the parts, pick up and align each leg, screw it into place, rotate the table, and finally flip it upright.
Inserting and screwing in a leg is particularly difficult. The robot must align parts it can’t fully see, control force, and repeat the process as the table’s position changes.

Congratulations to our top 3 teams and participants!
🥇 @merl_news: 10/29 points
🥈 @ramen_group_ai: 9 points
🥉 SayTheWord: 8 points
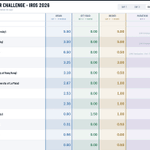
7 of 9 teams scored, but no one completed the full assembly. The results show just how challenging long-horizon loco-manipulation is.

The first Humanoid IKEA Assembly Challenge, co-organized with @UnitreeRobotics, @LightwheelAI and @singaporetech, took place at @ieeeiros.
9 global teams tested their loco-manipulation policies to assemble an IKEA UTTER children’s table. Full results ↓