

Assoc. prof. of CS at University of Maryland. Researcher in #PhysicalAI, #TrustworthyML, #EthicalAI, AI #Alignment, #AI for ALL.
College Park, MD
Joined September 2010
- Tweets2.4K
- Following2.8K
- Followers12K
- Likes7.5K





Cool work!

Research index (e.g. Google Scholar) is one of the largest collaborative systems where millions of human users build on each other's work across centuries.
How about we build something similar for async LLM agents?
We give agents a minimal hypertextual system. They asynchronously search for and read related work, cite the work that they find useful, and publish (mini-)papers.
Each search returns only the top k papers, ranked by relevance and a PageRank-like citation weight, which bounds the read cost of each agent to O(k), independent of agent count.
We show that performance effectively scales as we keep adding agents, and the system is robust to absence/failures of individual agents.
Congratulations @canondetortugas!

A super exciting announcement: In January 2027, I'll be joining @UCBerkeley as an assistant professor in EECS and Statistics.
I'll be recruiting PhD students and postdocs this cycle, starting Fall 2027. If you're interested the science of RL and deep learning, please apply.

Furong Huang retweeted

Coding agents write code for robot arms. We gave them a flying one 🚁
Can they handle manipulation tasks on a coaxial quad-tiltrotor (8 rotors, 4 tilting arms) with an arm and gripper?
Meet Fly-by-Code: built in simulation, the code runs on the real drone 🧵
Furong Huang retweeted

Continuing on my saga of going thru privacy and safety policies and design of personal assistants (i did instinct in a previous post) I was listening to this and going thru Meta’s design for Muse (tho having been @AIatMeta recently i had some idea), and I would say overall they have taken good measures and set good practice. However “even more encrypted” is really not a privacy/security goal or standard lol


Furong Huang retweeted
Can a robot hand learn a task from ONE human video, and still do it when the objects are somewhere else?
Meet Dex-One2Many 🖐️
Trained only in simulation from one video, it runs on a real robot hand, even from setups the video never showed 🧵
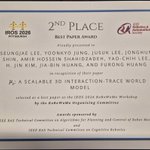
Real2Sim2Real, finally done right with “neuro-symbolic representations” and a new technique we call “controlled diversification”!
Introducing Dex-One2Many: from one human video in one setting to a robot that handles many configurations beyond the demonstration—different object positions, goal poses, and grasps.
How did we achieve such remarkable generalization? The key is controlled diversification—generating diverse training experiences in simulation while preserving the underlying task constraints.
The symbolic structure specifies what must hold at each stage; the neural policy discovers how to achieve it.
Procedurally:
(1) **Extract the task structure**. A vision-language model converts the demonstration into a sequence of scene graphs that capture the task’s relational structure: which object the hand should hold, what a tool should contact, and where an object needs to end up. These relationships preserve the task while leaving room for different configurations and motions.
(2) **Diversify under constraints**. We use these scene graphs to generate diverse, physically valid training states across different object positions and grasps, while preserving the task-defining relationships. The graphs also provide dense rewards that guide RL at each stage.
(3) **Learn through reinforcement learning**. We train the policy in these diversified simulation environments. Rather than imitating the demonstrated trajectory, the robot discovers different ways to accomplish the same task.
This is how one demonstration becomes a starting point for learning many ways to accomplish the same task.
Across five manipulation and tool-use tasks, the learned policies transfer zero-shot to a real dexterous hand, achieving 75% mean success on configurations not shown in the demonstration, compared with just 4% for the next-best baseline—with no real-world fine-tuning.
A wonderful collaboration with @jusukle, @JayLEE_0301, @jbhuang0604, and the entire team!
Project: dex-one2many.github.io/
Paper: arxiv.org/abs/2610.12470
#Robotics #NeuroSymbolicAI #ReinforcementLearning #DexterousManipulation
Real2Sim2Real, finally done right with neuro-symbolic representations!
Introducing Dex-One2Many: from one human video in one setting to a robot that generalizes to configurations beyond the demonstration—different object positions, goal poses, and grasps.
The key to the remarkable generalization is the abstraction. Dex-One2Many extracts the task’s relational structure into “scene graphs”, then uses them to generate diverse training states and rewards for RL in simulation. The graphs specify what must hold at each stage (constraints, our inductive bias); RL discovers how to achieve it across different configurations.
One demonstration opens up many ways to accomplish the same task—and the learned policy transfers zero-shot to a real dexterous hand.
Project: dex-one2many.github.io

Furong Huang retweeted
OpenAI reported ~10,000 agents working on Navier–Stokes.
That raises a question for teams of any size: how should agents work together, and which ways of working are worth reusing?
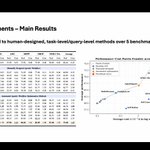
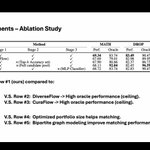
Our insight: a workflow that loses on average can solve what the winner misses.
FlowBank learns which workflows to keep and when to use each.
Accepted at #NeurIPS2026
#AgenticAI
A 🧵
Furong Huang retweeted

FlowBank precomputes a diverse workflow portfolio and picks the right one per query, giving query-level adaptivity at task-level cost

OpenAI reported ~10,000 agents working on Navier–Stokes.
That raises a question for teams of any size: how should agents work together, and which ways of working are worth reusing?
Our insight: a workflow that loses on average can solve what the winner misses.
FlowBank learns which workflows to keep and when to use each.
Accepted at #NeurIPS2026
#AgenticAI
A 🧵
Furong Huang retweeted

🤖 Frontier models like GPT 6 Astra are getting surprisingly good at controlling robots. The results are exciting, but deploying frontier models on robots comes with substantial inference cost and latency.
Can we distill these capabilities into compact models that run locally?
We open-source 🥑Guava — a framework for distilling frontier models into compact robot agents, using purely simulation interaction data, no real-world data required!
With only ~2K simulation trajectories, we finetuned Qwen3.5 into Guava-4B, with:
🤖 90.0% real-world success vs. 93.3% for GPT-5.4
⚡ 7.1× lower model-call latency with local inference
🌎 Sim-to-real transfer without real-world fine-tuning
🧠 Generalization to unseen tasks and object configurations
🔄 Closed-loop recovery from execution failures
Paper + code + project page:
guava-harness.github.io/
🎥 See Guava in action below.
Joint efforts from @haowenssr, @xiruili7_li, @ShaoxiongYao, Peng Shi, @zhoutianyi, @jbhuang0604 , @furongh and @maojiayuan.
Furong Huang retweeted

Super simple way to use open models in Claude Code, CODEX and other harnesses! Very useful!

Furong Huang retweeted

🙌 Thanks Furong for highlighting FlowBank! I'll be at NeurIPS in Atlanta this year. If you're working on agent harnesses or multi-agent system design, come find me and let's chat!
OpenAI reported ~10,000 agents working on Navier–Stokes.
That raises a question for teams of any size: how should agents work together, and which ways of working are worth reusing?
Our insight: a workflow that loses on average can solve what the winner misses.
FlowBank learns which workflows to keep and when to use each.
Accepted at #NeurIPS2026
#AgenticAI
A 🧵
7/n
For those building agent systems: what signals should tell an agent to reuse a workflow, adapt it, or design a new one?
8/n
Huge congratulations to the team: Lingzhi Yuan @lingzhi_yuan, Chenghao Deng @chenghao_deng, Fangxu Yu @nerv_599164778, Souradip Chakraborty @SOURADIPCHAKR18, and Mohammad Rostami @MRostami_Pn. 💐
Paper: arxiv.org/abs/2606.11290
Project: agentic-flowbank.github.io/
Code: github.com/umd-huang-lab/Flo…
